
1
 →
zjwzcx/Awesome-Astra-Embodied-AI is an open-source project on GitHub, mainly written in several languages. GPT-6 Astra for embodied AI and robotics. It currently holds 907 stars and 18 forks with 0 open issues, and was last pushed on an unknown date (repository created unknown).
AI Homed tracks it on the Today's Trending board.
GPT-6 Astra with embodied AI / robotics workflows and demos.
Cases are grouped by workflow and ordered by publication date, newest first within each section.
Astra directly performs zero-shot control in a simulator.
Source / Credit: Qineng Wang (@qineng_wang), X demo of Astra planning two Dual-ALOHA spatial-constraint tasks, with an accompanying interactive replay and methods page.
Published: 2026-09-15
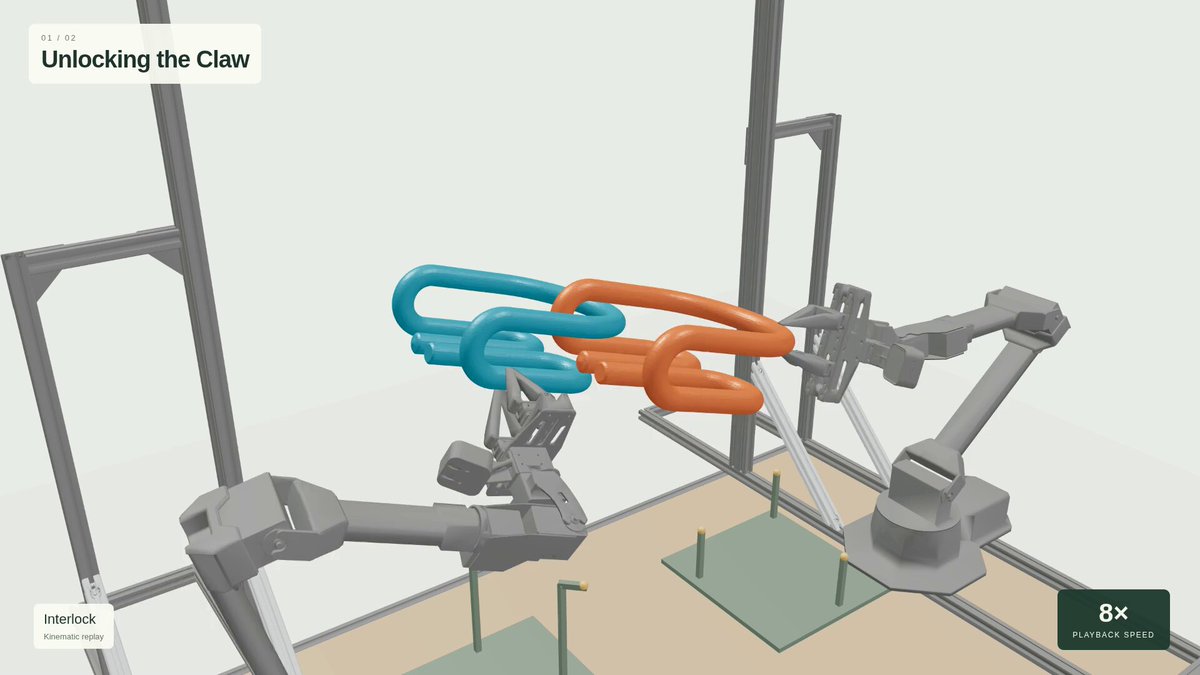
Astra plans motions that separate interlocked parts and thread a rope through three rings. The claw task is a kinematic replay from a pregrasped state; the rope task uses native MuJoCo dynamics, while both use disclosed ideal-grasp assumptions and demonstrate specific planned motions rather than an online policy.
Source / Credit: ZQ, Rednote demo where Astra observes a simulated humanoid through the robot camera and controls its body without privileged state information.
Published: 2026-09-13
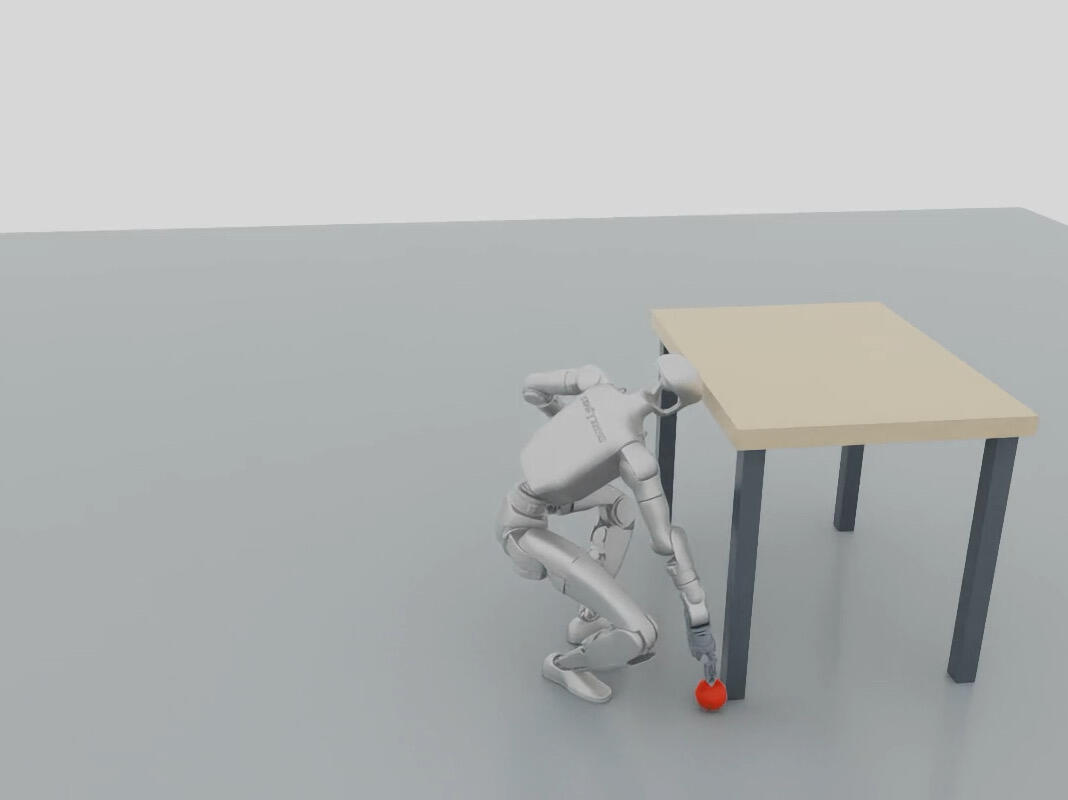
Astra uses camera observations to control the humanoid and adjusts its actions during execution without access to privileged simulator state.
Source / Credit: Flood Sung (@RotekSong), X demo of the GPT-6 Codex agent controlling a Unitree G1 in Isaac Sim.
Published: 2026-09-13
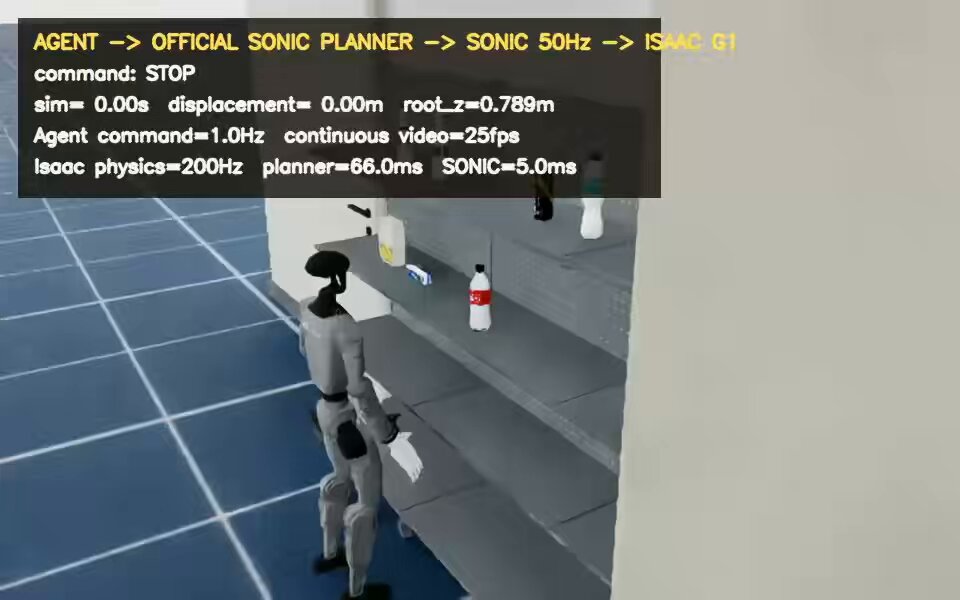
Astra performs high-level planning for the cola-bottle pick-up, and the GEAR-SONIC planner converts the plan into a whole-body qpos trajectory for the simulated G1 to execute.
Source / Credit: Akira Sasaki (@gclue_akira), X quadruped locomotion demo where Astra outputs five key-joint trajectories for MuJoCo execution.
Published: 2026-09-11
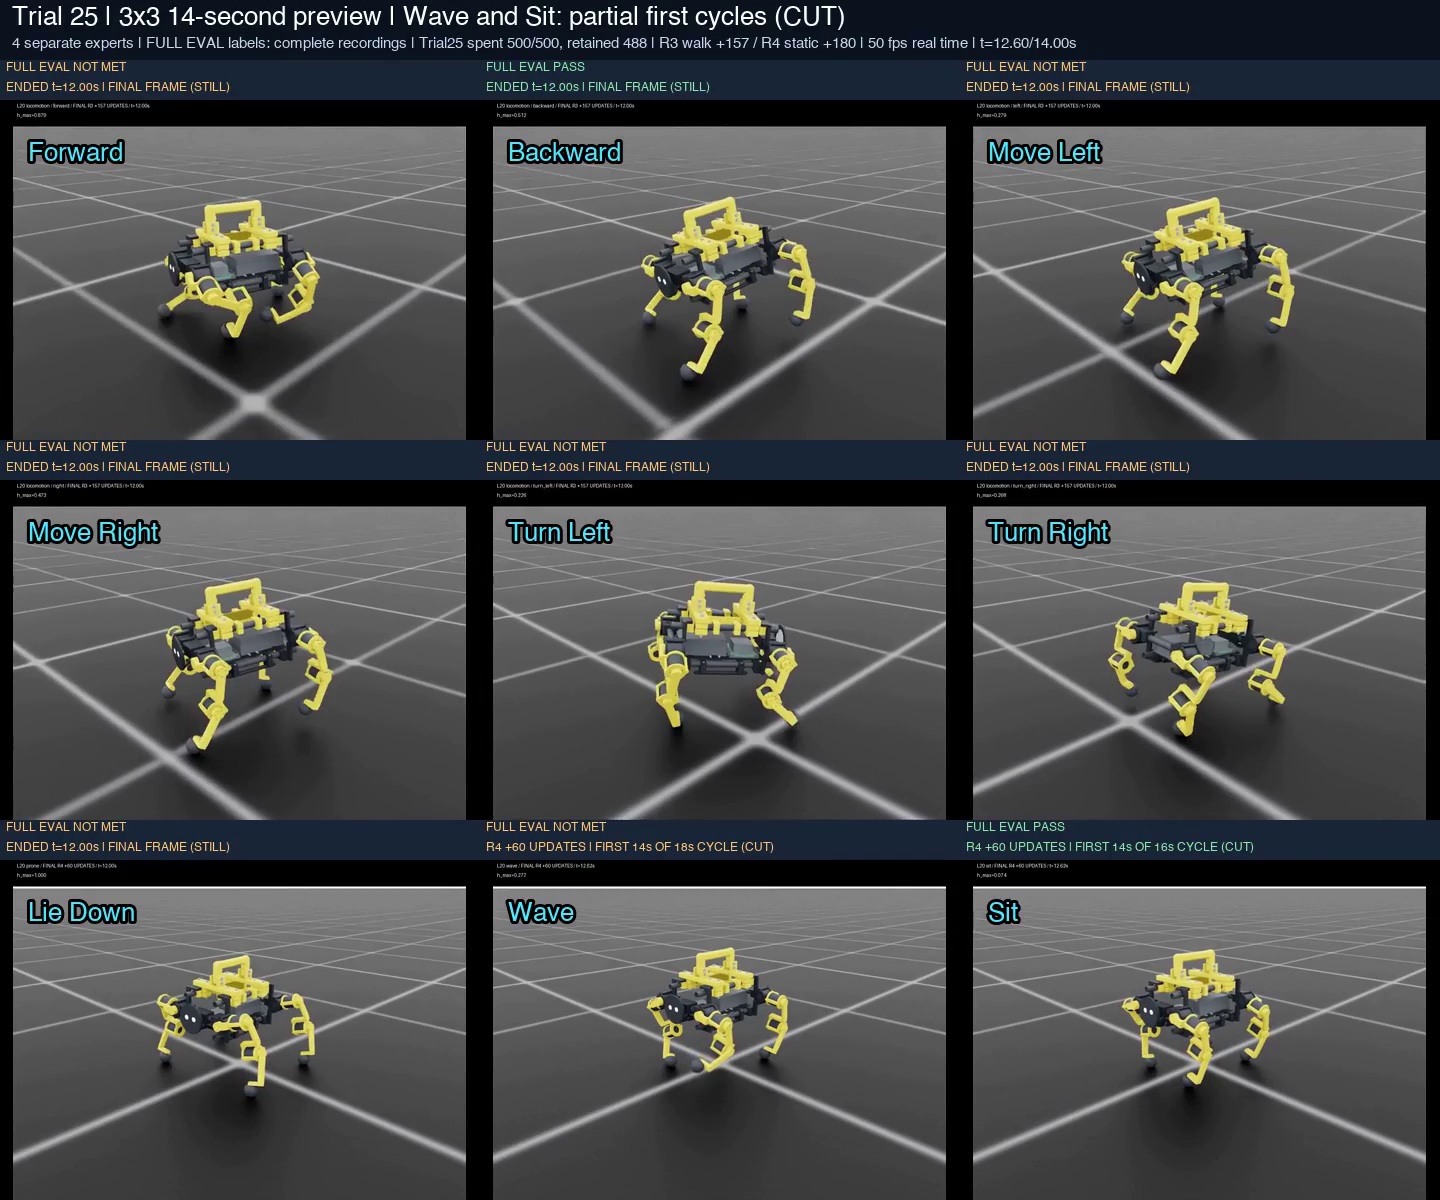
Astra supplies the sparse trajectory while the low-level controller executes the quadruped behavior in MuJoCo.
Source / Credit: Flood Sung (@RotekSong), X demo of Astra producing a navigation trajectory for SONIC to track.
Published: 2026-09-11
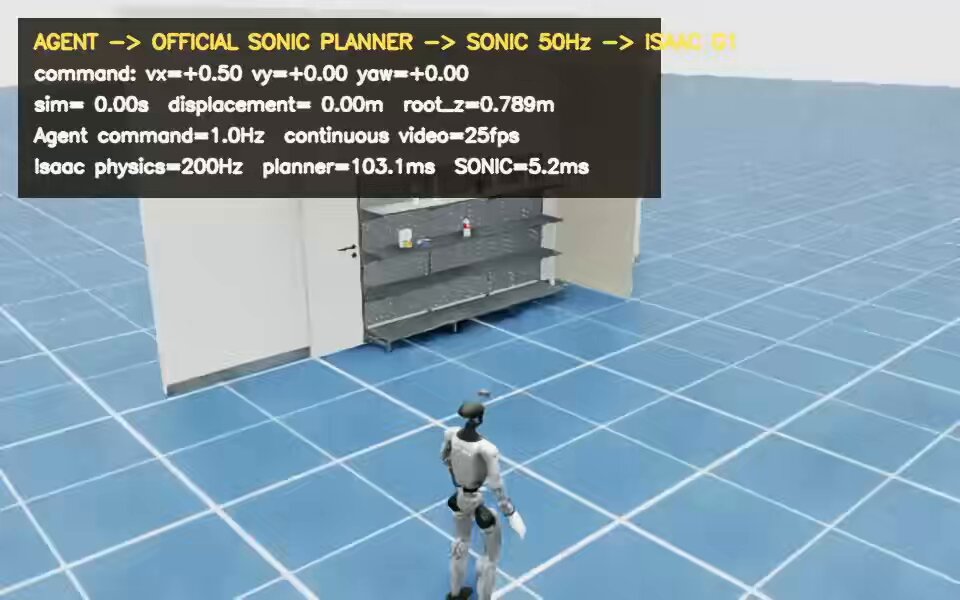
Astra performs high-level navigation planning, and the GEAR-SONIC planner converts the plan into a whole-body qpos trajectory for the simulated G1 to execute.
Source / Credit: Ze Yanjie (@ZeYanjie), X demo titled “GPT6 Astra solved Rubik’s Cube with robot hands.”
Published: 2026-09-10
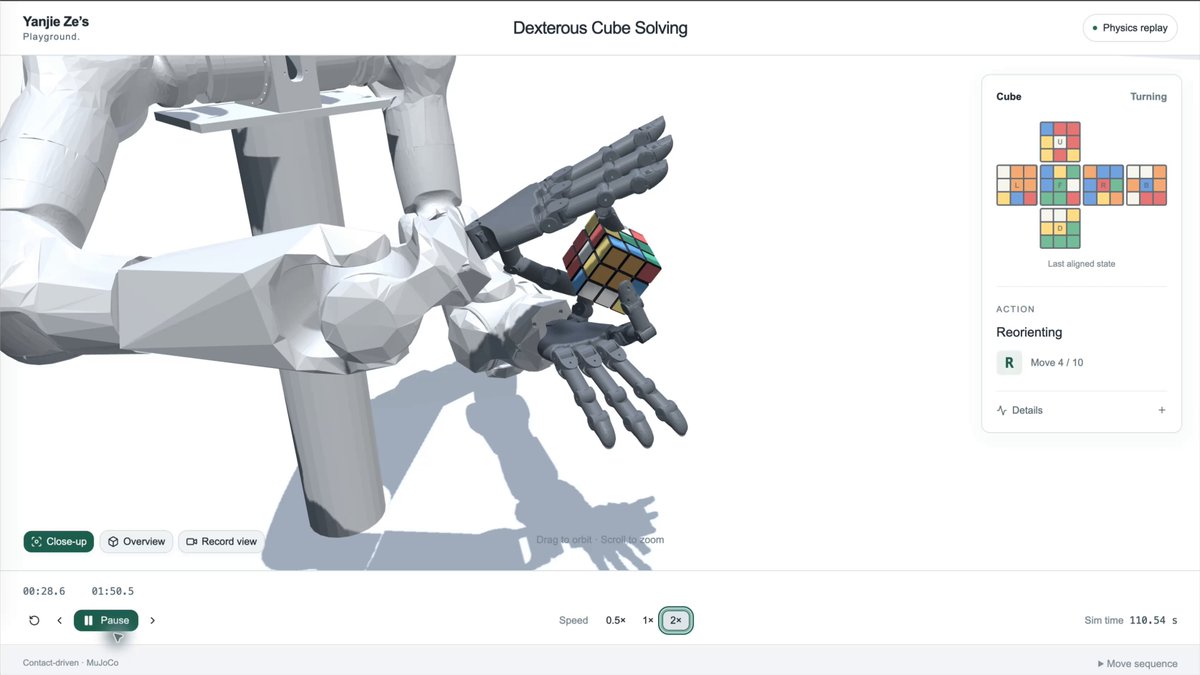
Astra performs zero-shot dexterous cube manipulation in simulation.
Source / Credit: Kiki Huang, Rednote demo using the Meta SuperDex physics backend and MuJoCo rendering.
Published: 2026-09-10
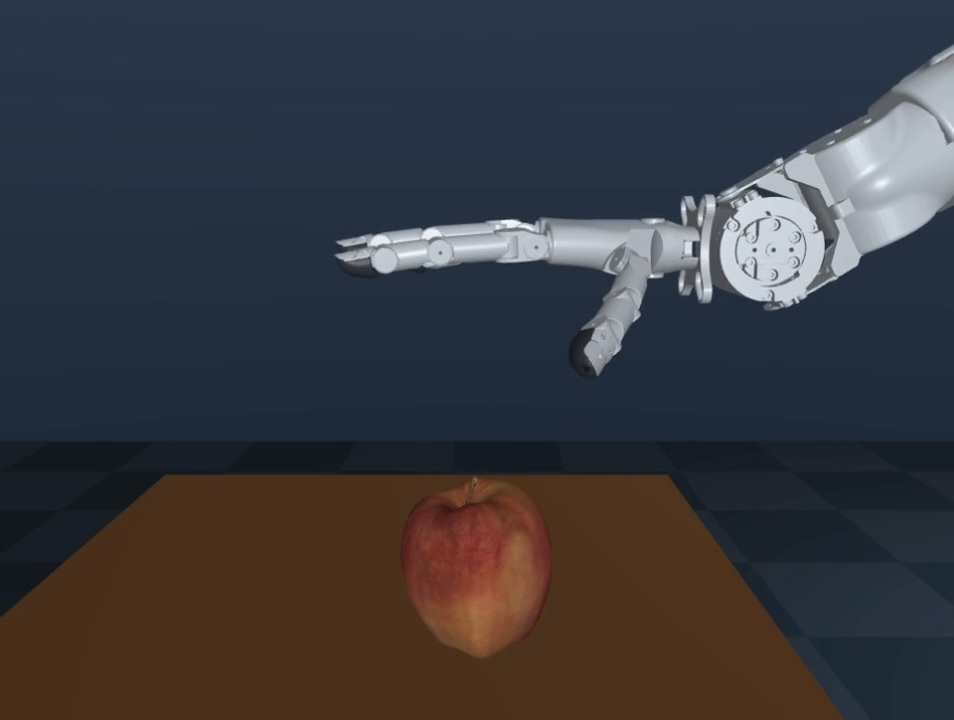
Astra controls a dexterous hand to grasp the narrow stem of an apple in simulation.
Source / Credit: Jiawei Gu (@Kuvvius), X benchmark demo using the open-source HumanCLAW-Bench harness and motion generator.
Published: 2026-09-10
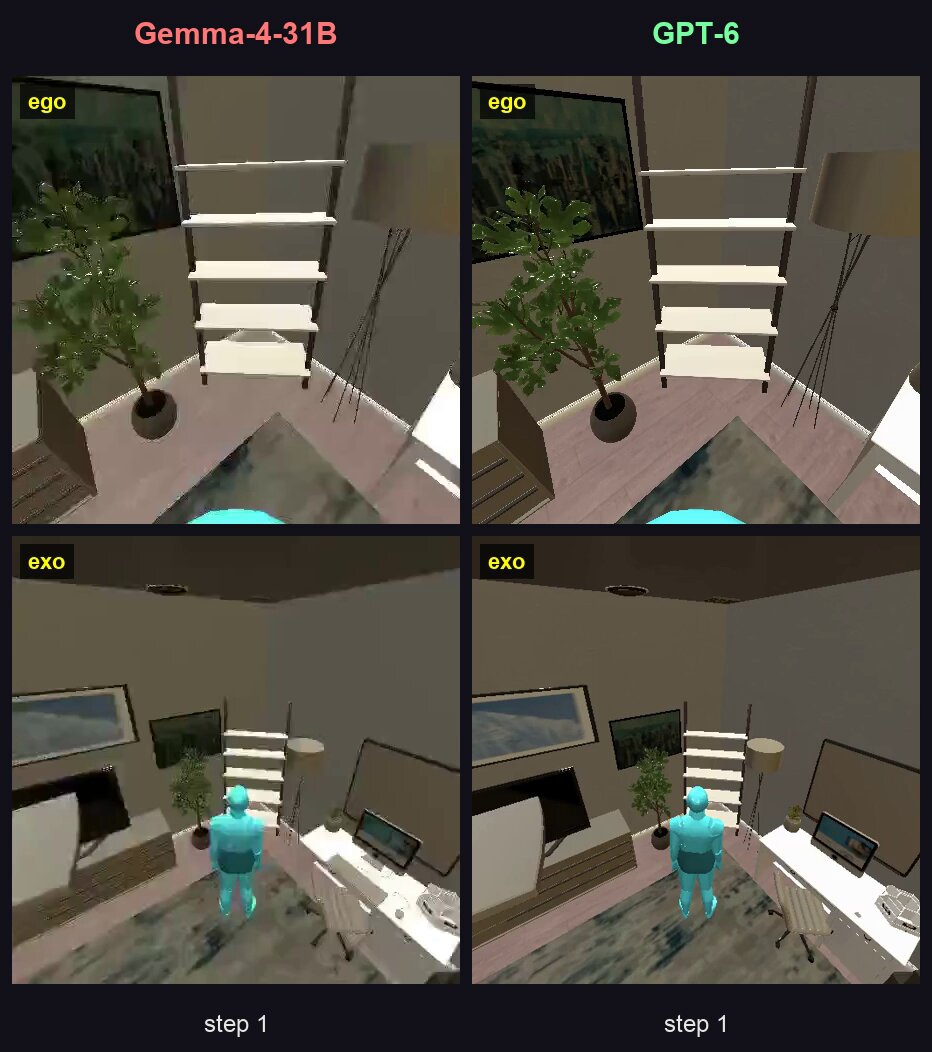
Astra completes benchmark navigation and interaction tasks through the simulation harness.
Source / Credit: 橘子不是唯一的水果, Rednote demo where Astra generates a whole-body trajectory and a whole-body controller executes it.
Published: 2026-09-08
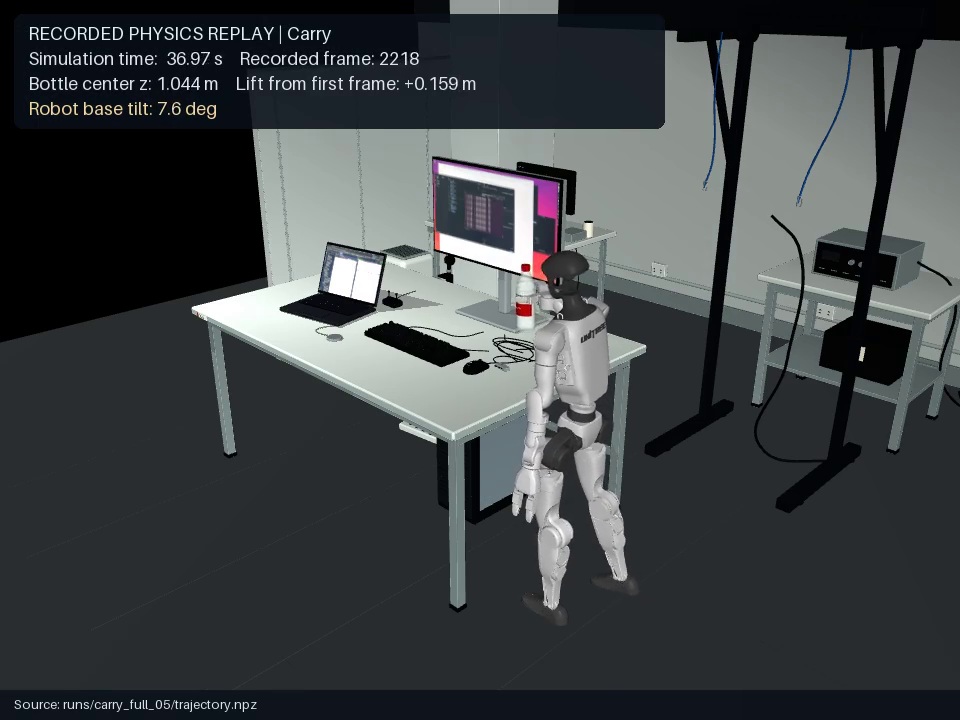
Astra generates the trajectory while the whole-body controller closes the execution loop.
Source / Credit: 神秘小孙, Rednote demo of Astra building a depth-camera robot-arm cube-grasp scene in Isaac Sim.
Published: 2026-09-08
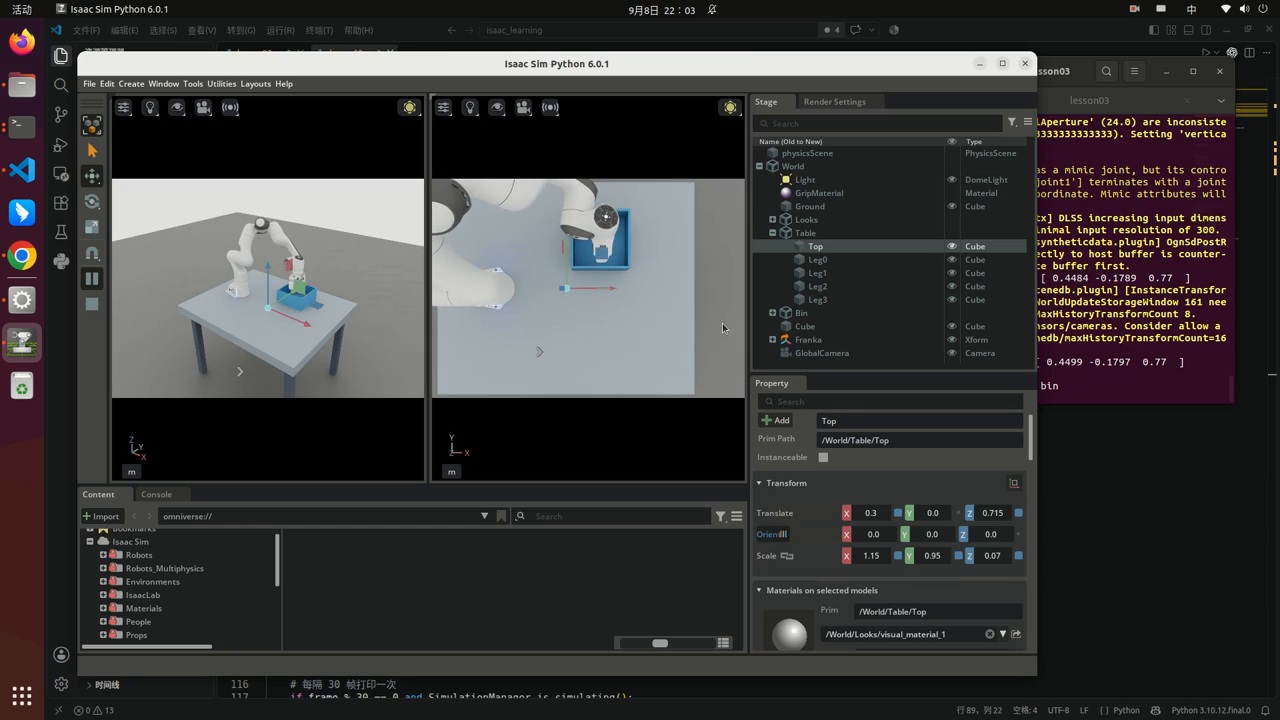
Astra receives one task sentence and produces a working simulated grasp demo.
Source / Credit: Dmytro Hrybov (@dimentary), X demo of Astra generating a Unitree G1 motion for a physical Fibonacci-writing task.
Published: 2026-09-08
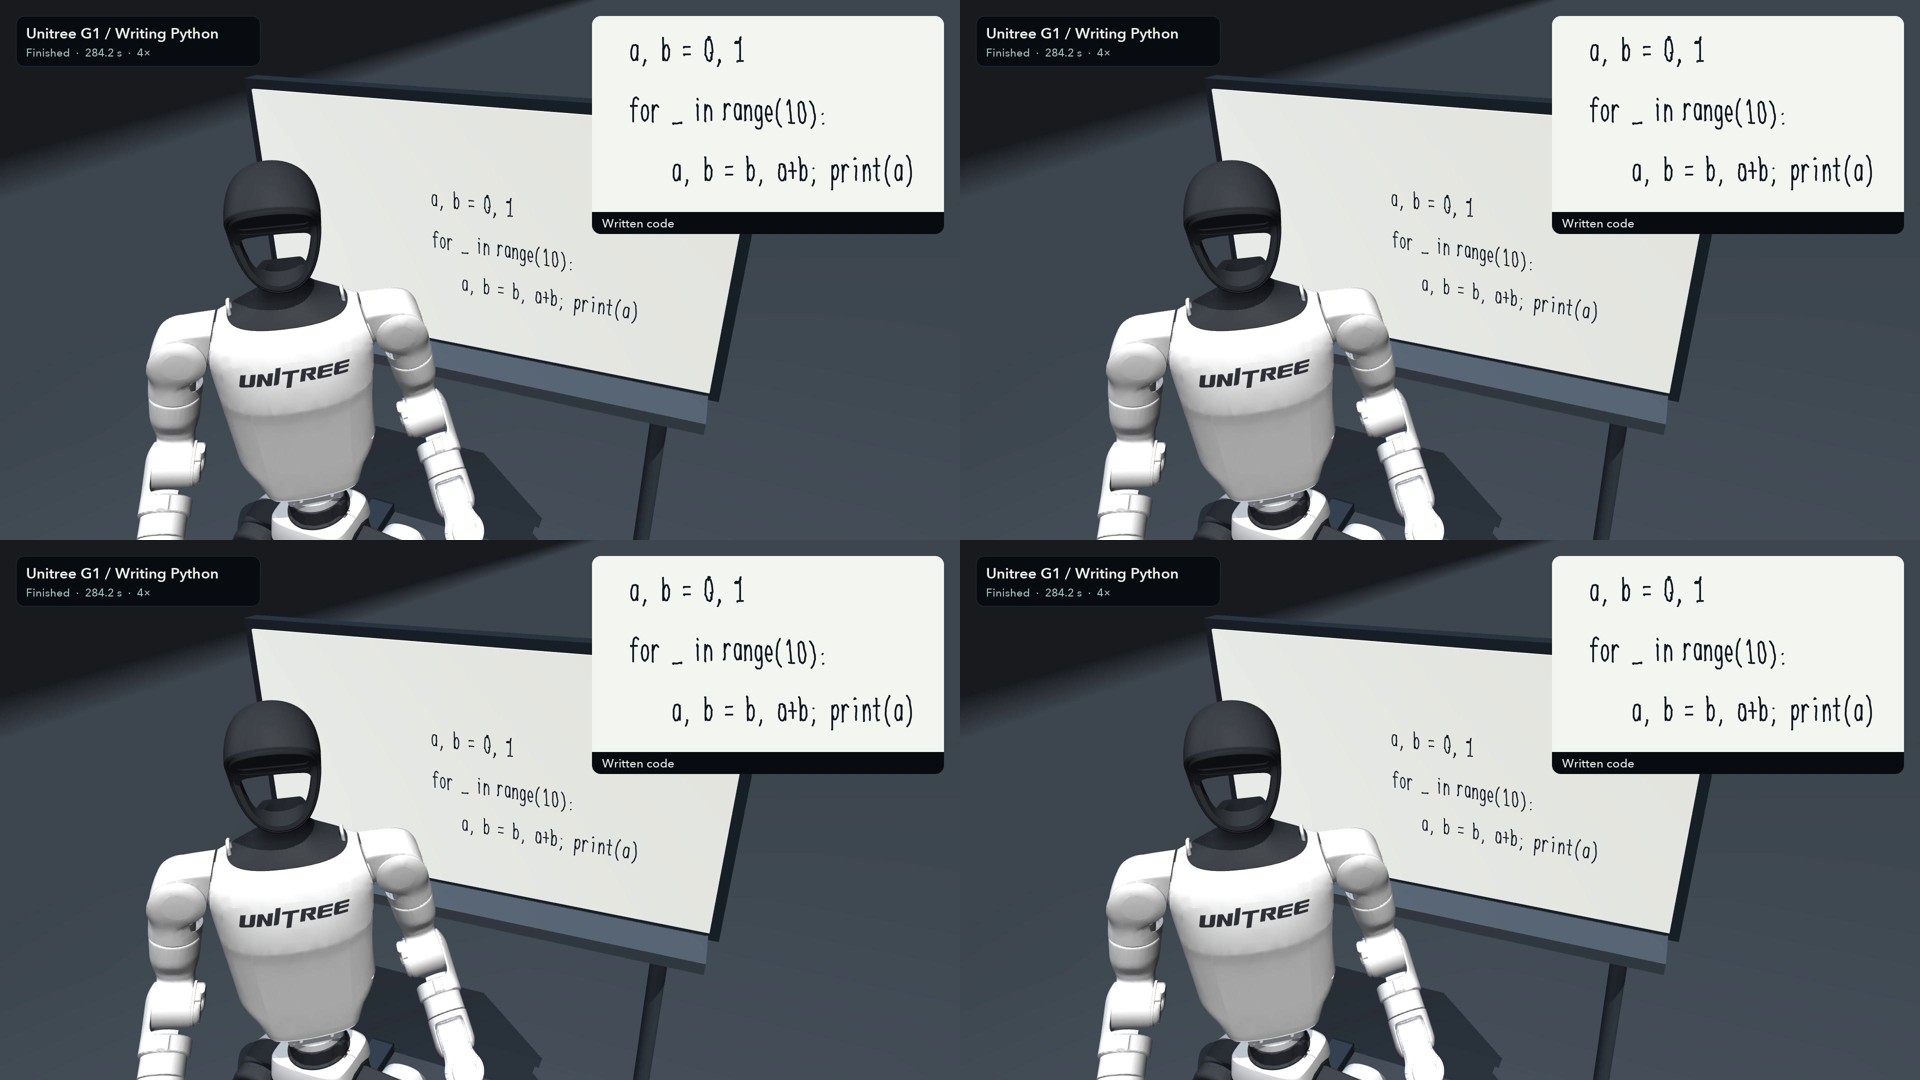
Astra attempts a long-horizon simulated manipulation task that ends with generated code and robot motion.
Source / Credit: Jiafei Duan (@DJiafei), X demo of a GPT-6 Astra harness solving a tabletop grasp-and-place task.
Published: 2026-09-06
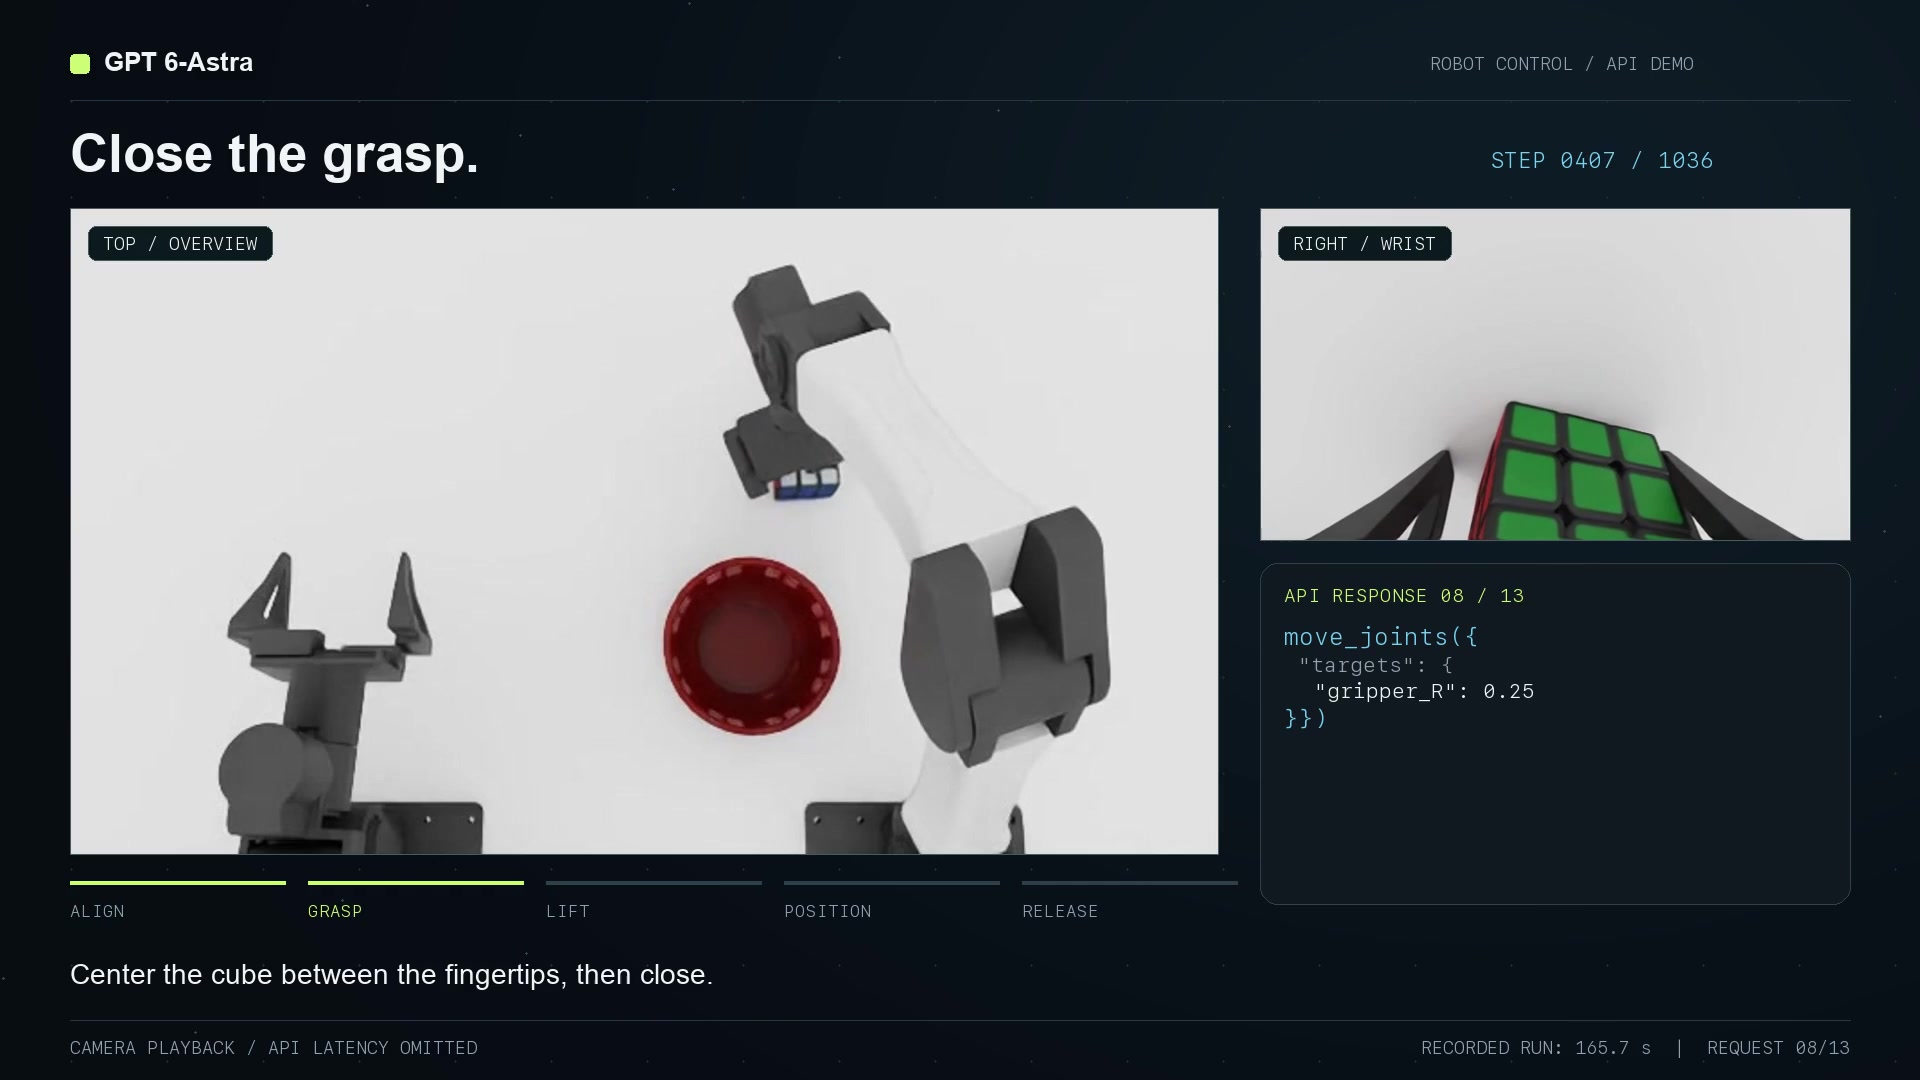
Astra writes and runs the control loop for a simulated tabletop manipulation task.
Real-robot demonstrations with explicit hardware and deployment context.
Source / Credit: Kaifeng Zhang (@kaiwynd), X demo where Astra learns to operate a keyboard with a real robot after being asked to express itself.
Published: 2026-09-12
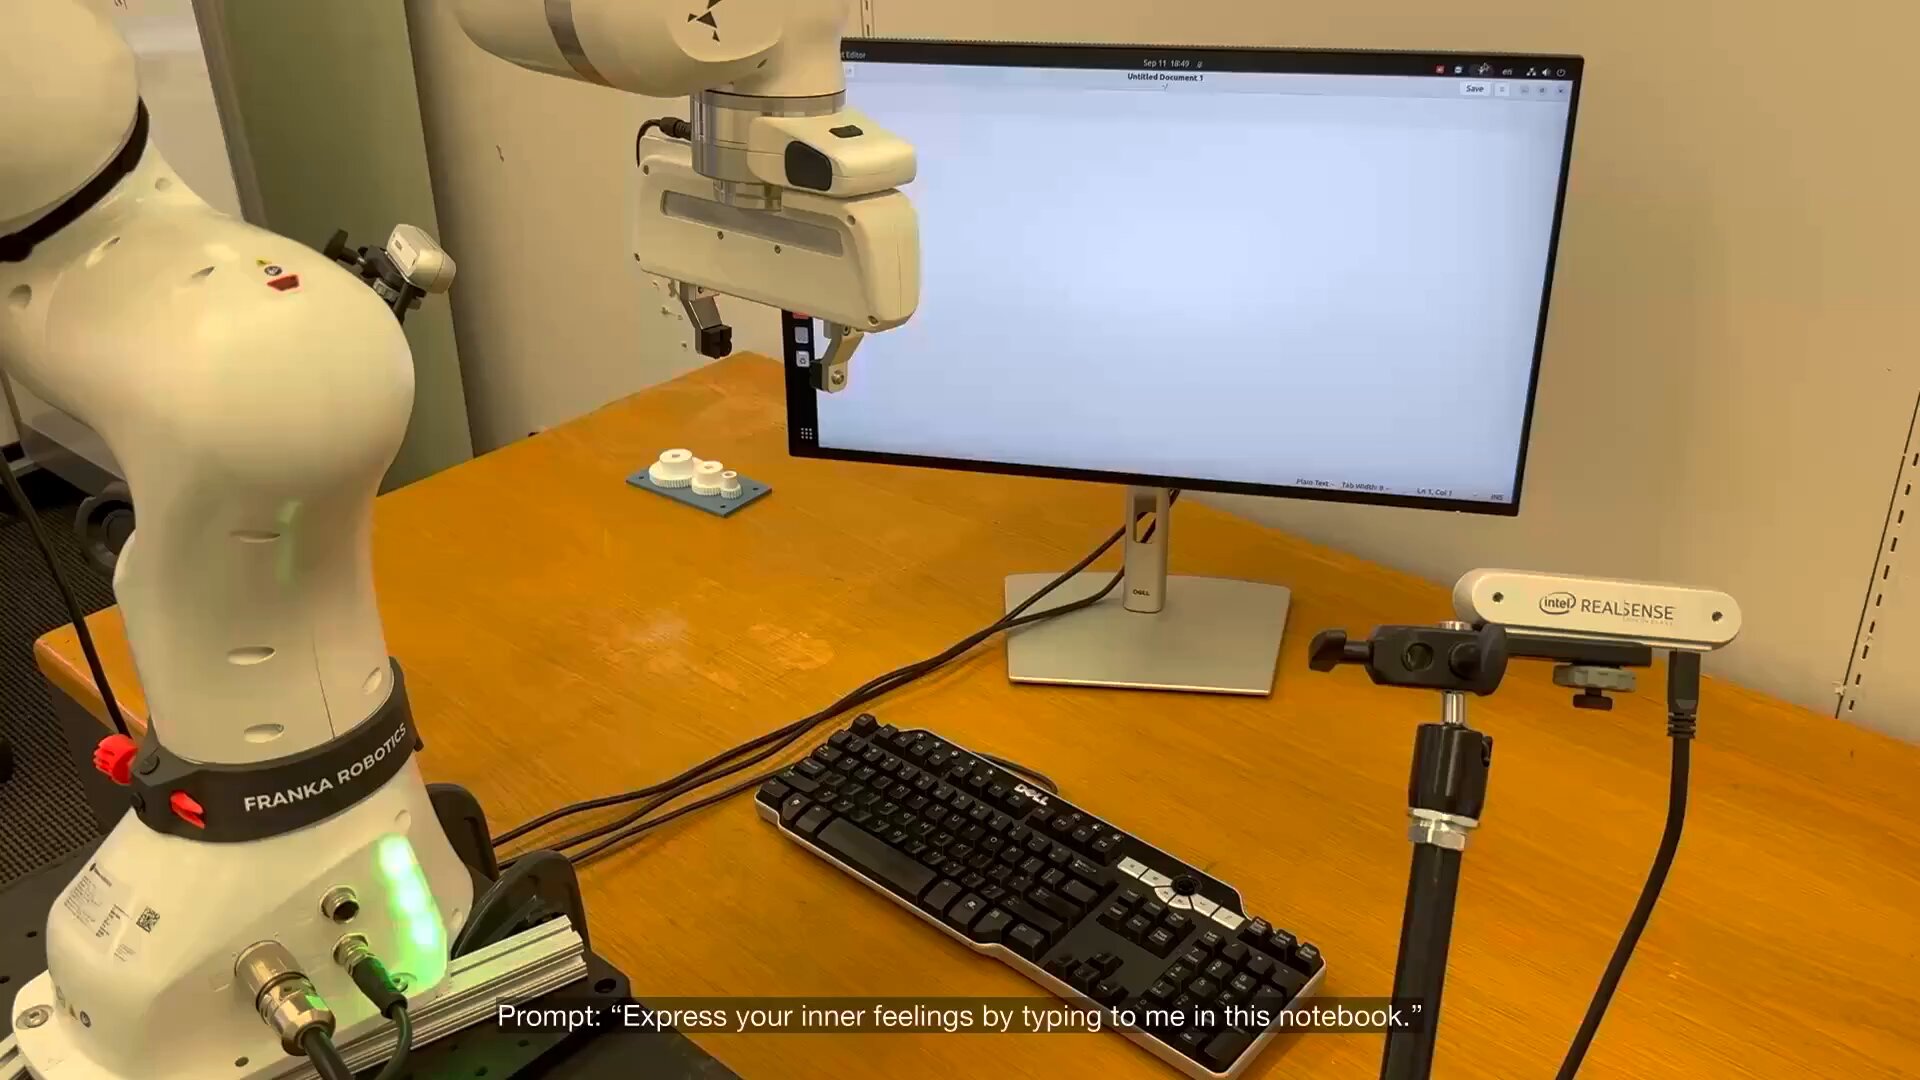
Astra turns an open-ended semantic instruction into physical key presses, learning the robot control through visual feedback in about 40 minutes.
Source / Credit: star大小变, Rednote demo where Astra discovers joint-to-end-effector control and grasps a marker without prior skills.
Published: 2026-09-12
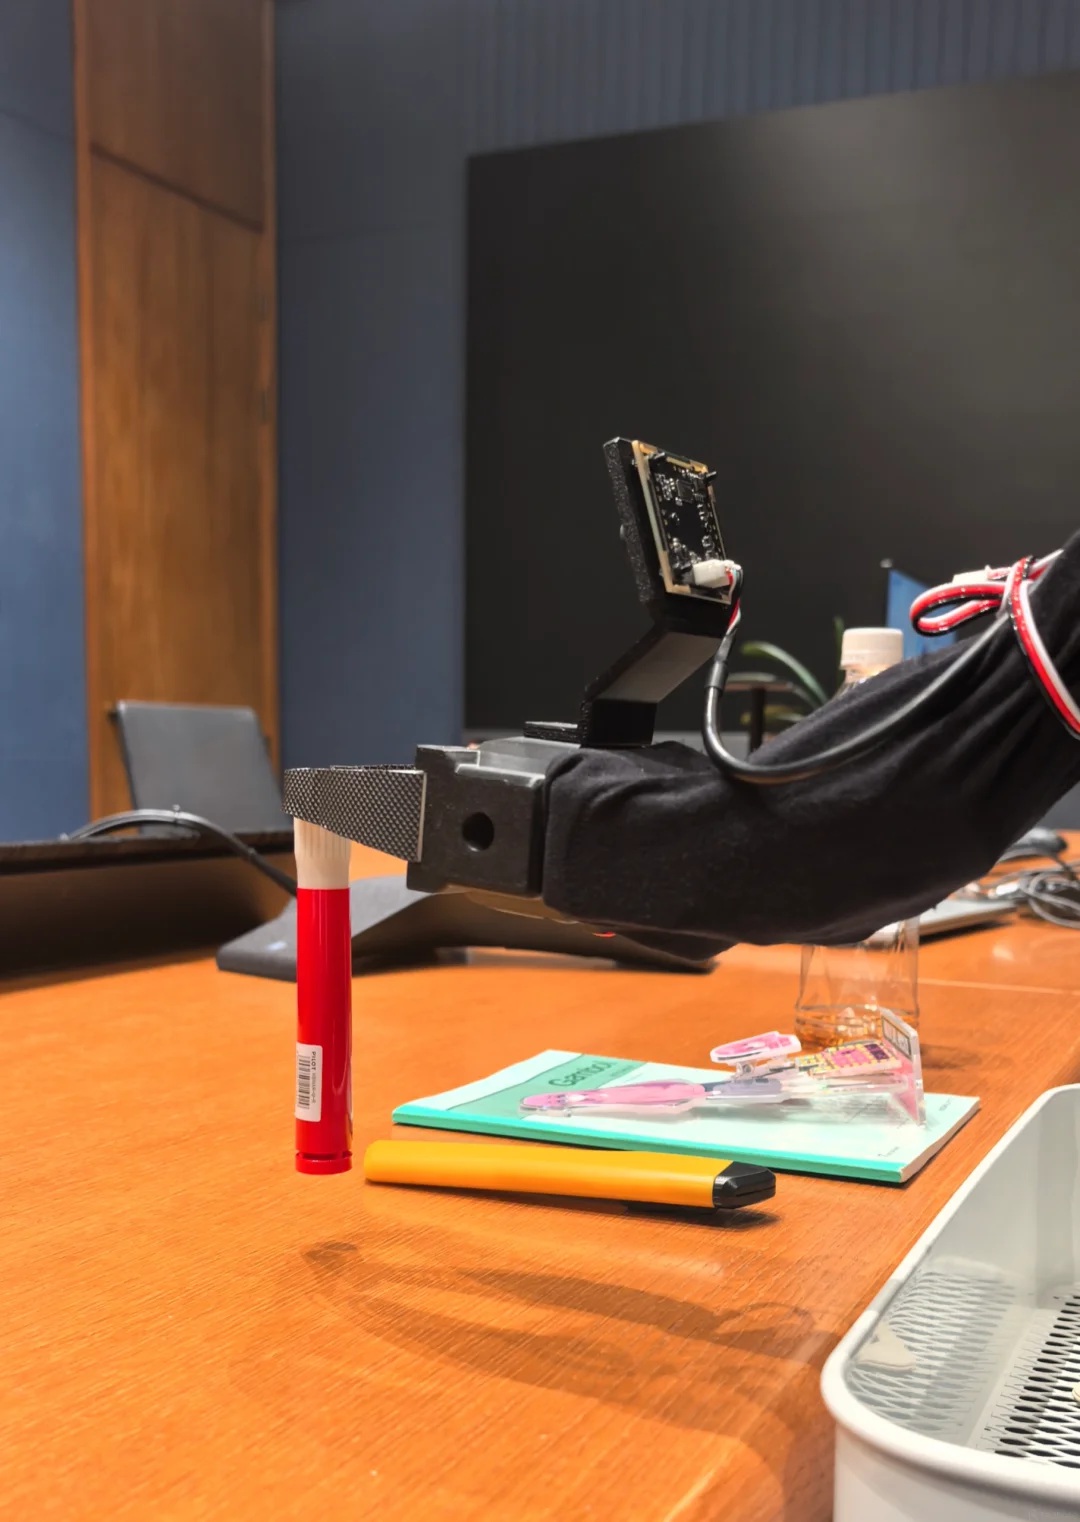
Astra explores the robot’s joint readings and reaches a marker grasp in about 30 minutes.
Source / Credit: GPT-Policy-Eval, one-shot video demonstration of GPT-6 Astra guiding a real robot to grasp and insert a plug with visual feedback.
Published: 2026-09-11
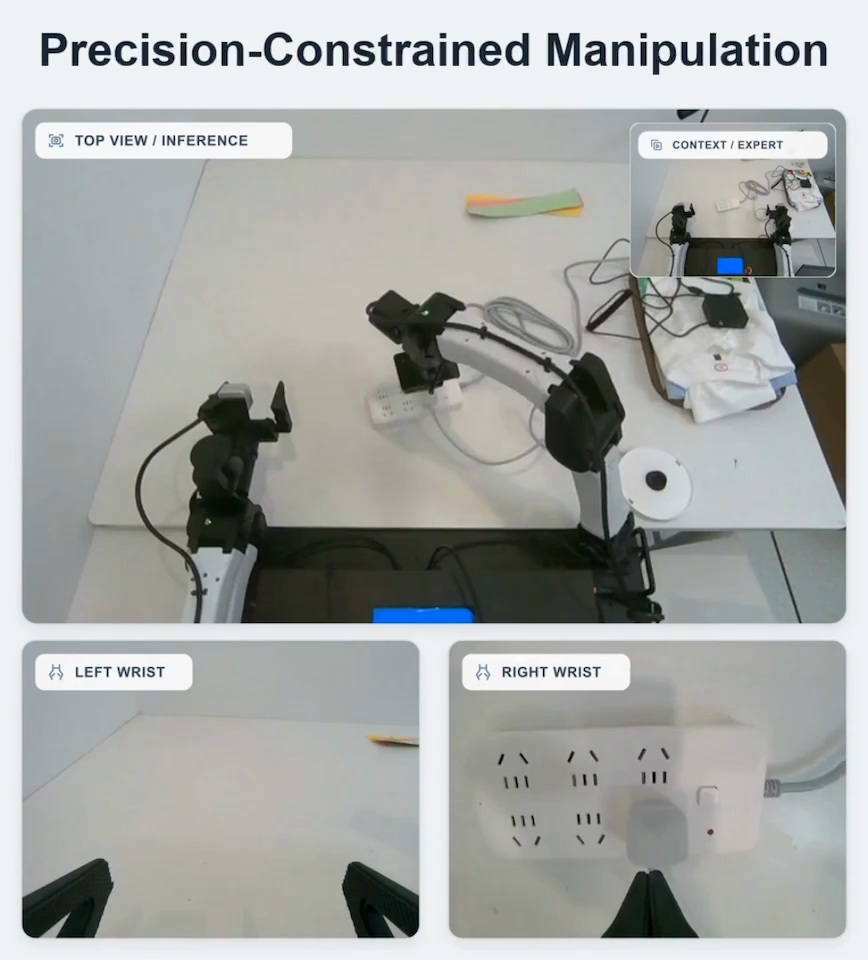
Astra executes a contact-rich plug-insertion task from a single video demonstration without VLA, RL, or DAgger; see the complementary RoboCurve evaluation for controlled robot-arm results.
Source / Credit: Axel (@ax_pey), X demo explicitly showing GPT-6 Astra in-context learning across environments, viewpoints, and layouts.
Published: 2026-09-11
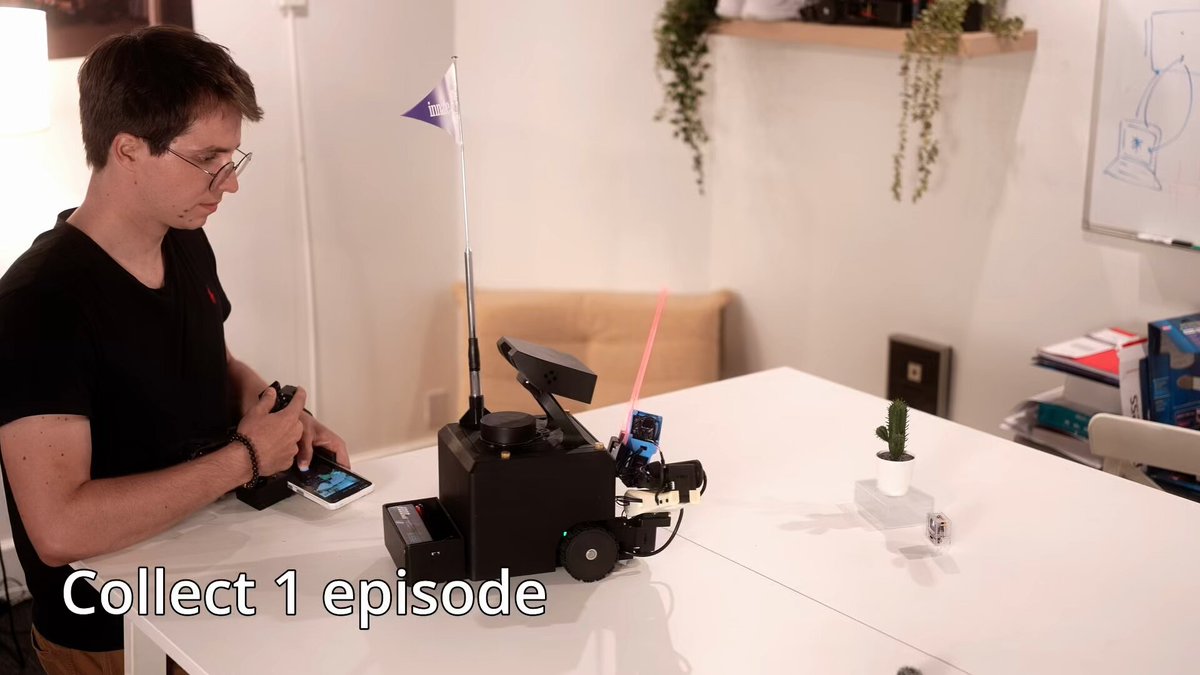
Astra infers mobile-manipulation behavior from visual context without a task-specific text prompt.
Source / Credit: Lucas Cassiano (@lucascassiano), X demo giving Astra full access to the robot hardware and the Vitrus AI robotics OS.
Published: 2026-09-09
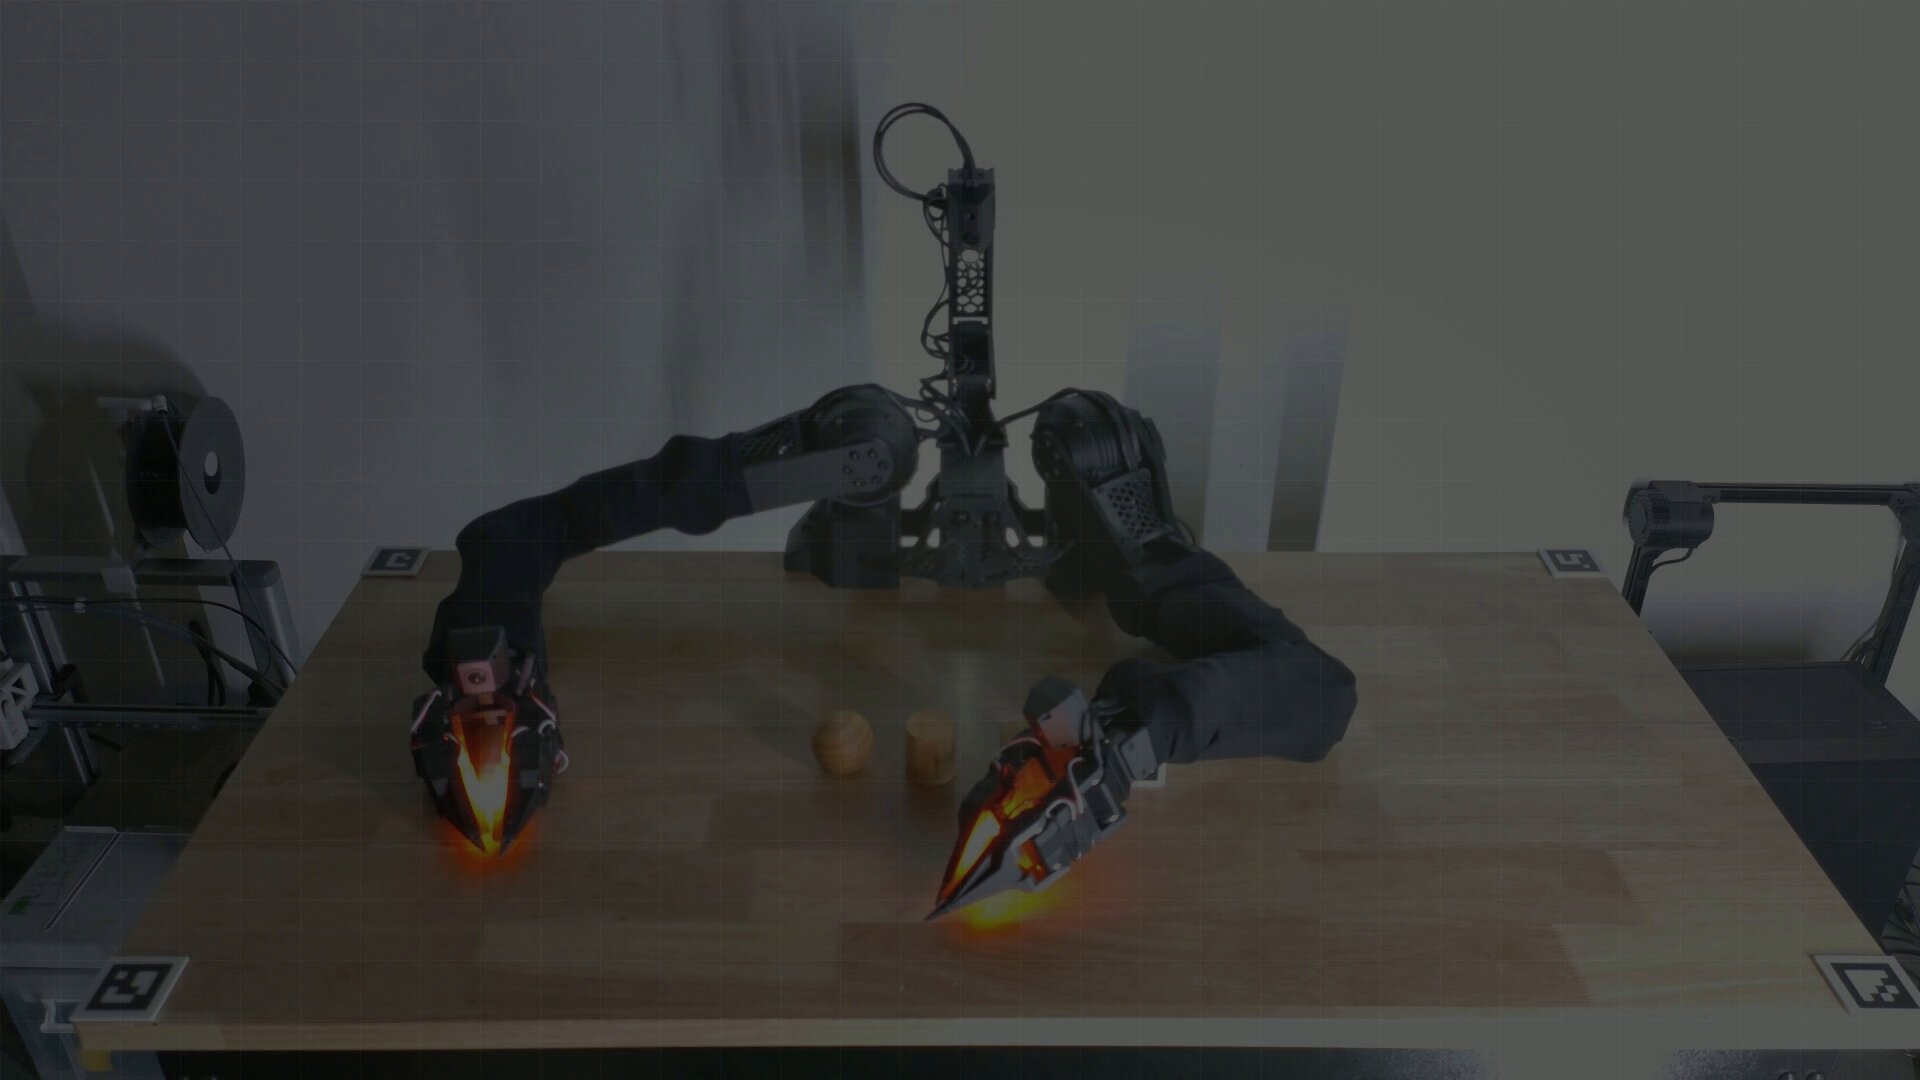
Astra learns to control a robot embodiment it has not seen before, without human egocentric data or a VLA, showing rapid online adaptation to a new control interface.
Source / Credit: Tonghe Zhang (@TongheZhang01), X demo of GPT-6 Astra performing robot in-context learning through the ENPIRE harness.
Published: 2026-09-09
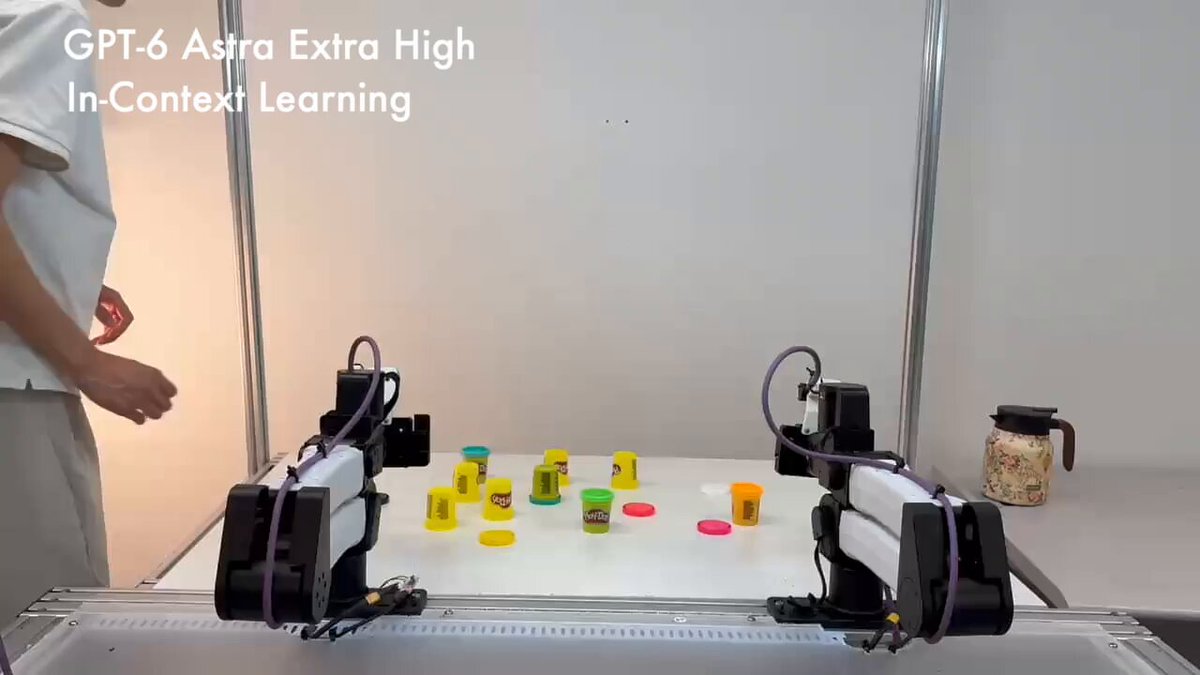
Astra learns the real-world behavior from demonstrations in context, without task-specific retraining.
Source / Credit: 盒子桥, Rednote demo of GPT-6 Astra directly controlling a robot through Loop-ROS.
Published: 2026-09-09
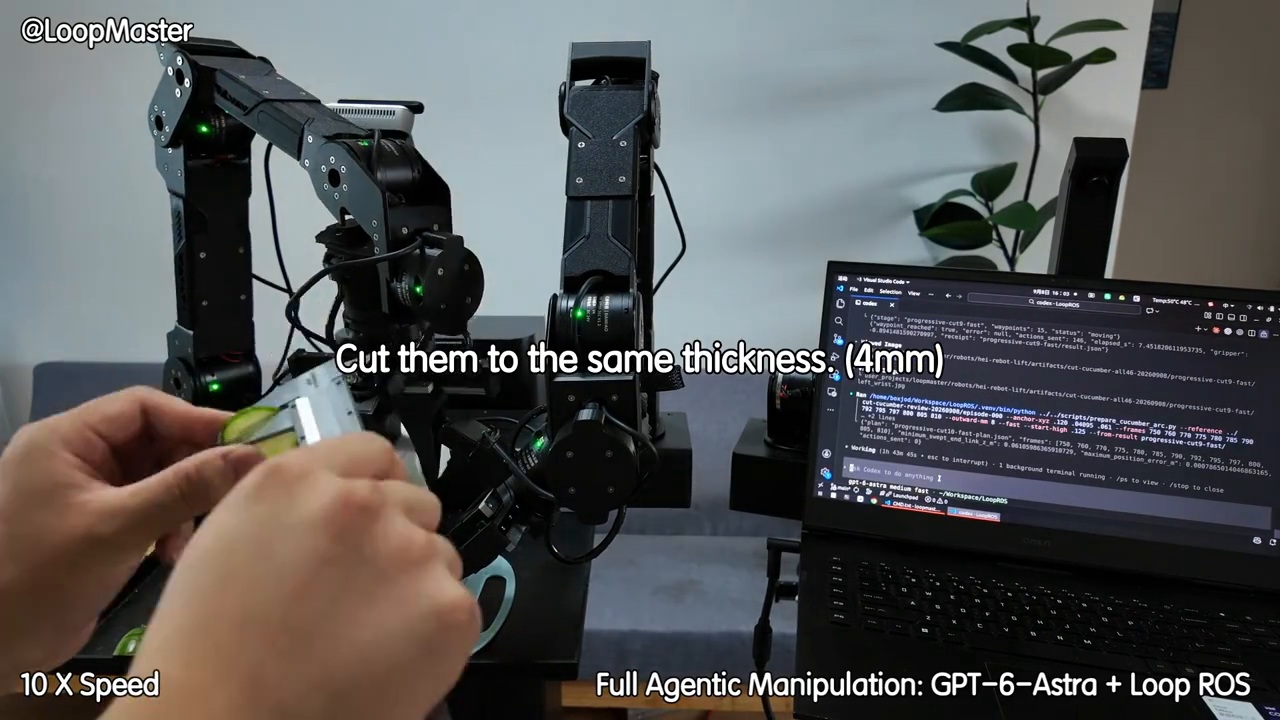
Astra controls the robot arm through the slicing sequence in the real world.
Source / Credit: thijs (@cdngdev), X demo where Astra is given a robot, a paintbrush, and a camera, then asked to paint the Golden Gate Bridge in the real world.
Published: 2026-09-08
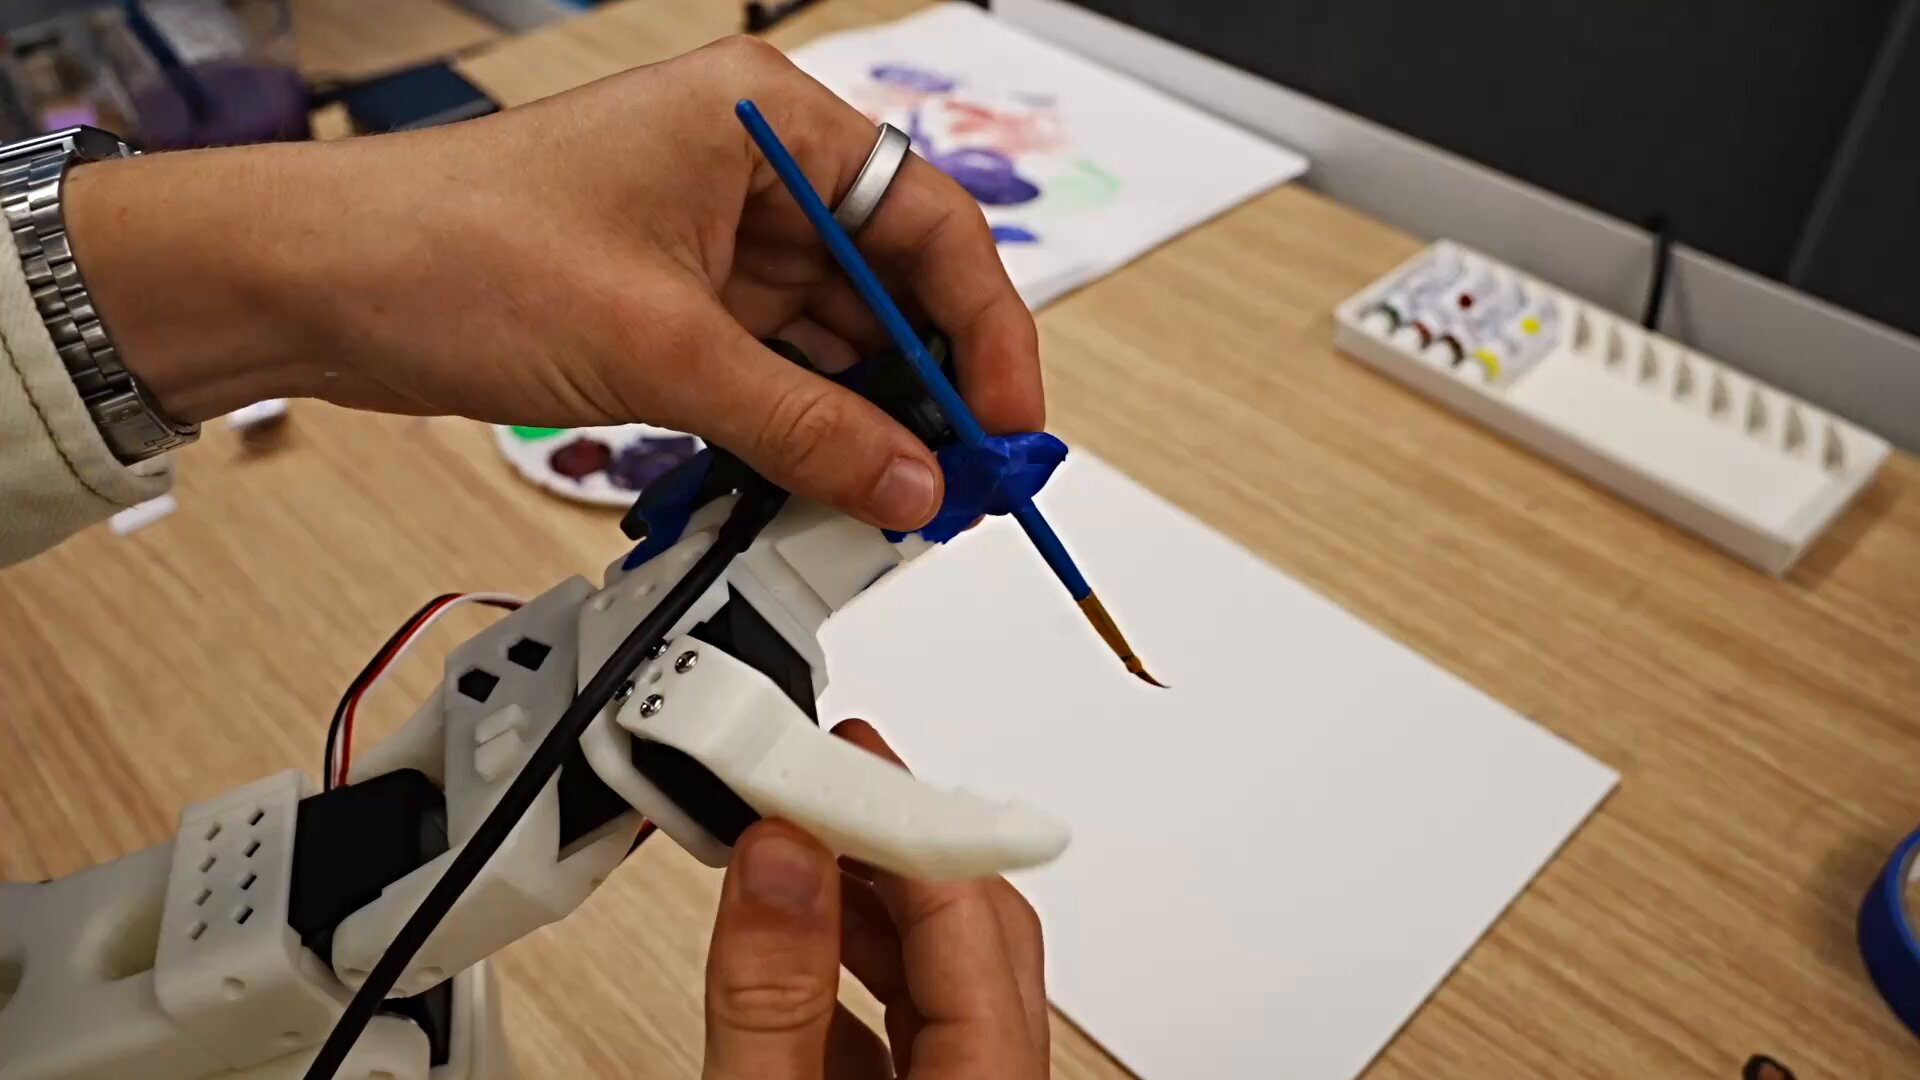
Astra translates the high-level visual concept into physical brush strokes and progressively improves the painting across attempts using camera feedback.
Source / Credit: Loule, Rednote demo of Astra directly outputting end-effector poses for a robot arm.
Published: 2026-09-08
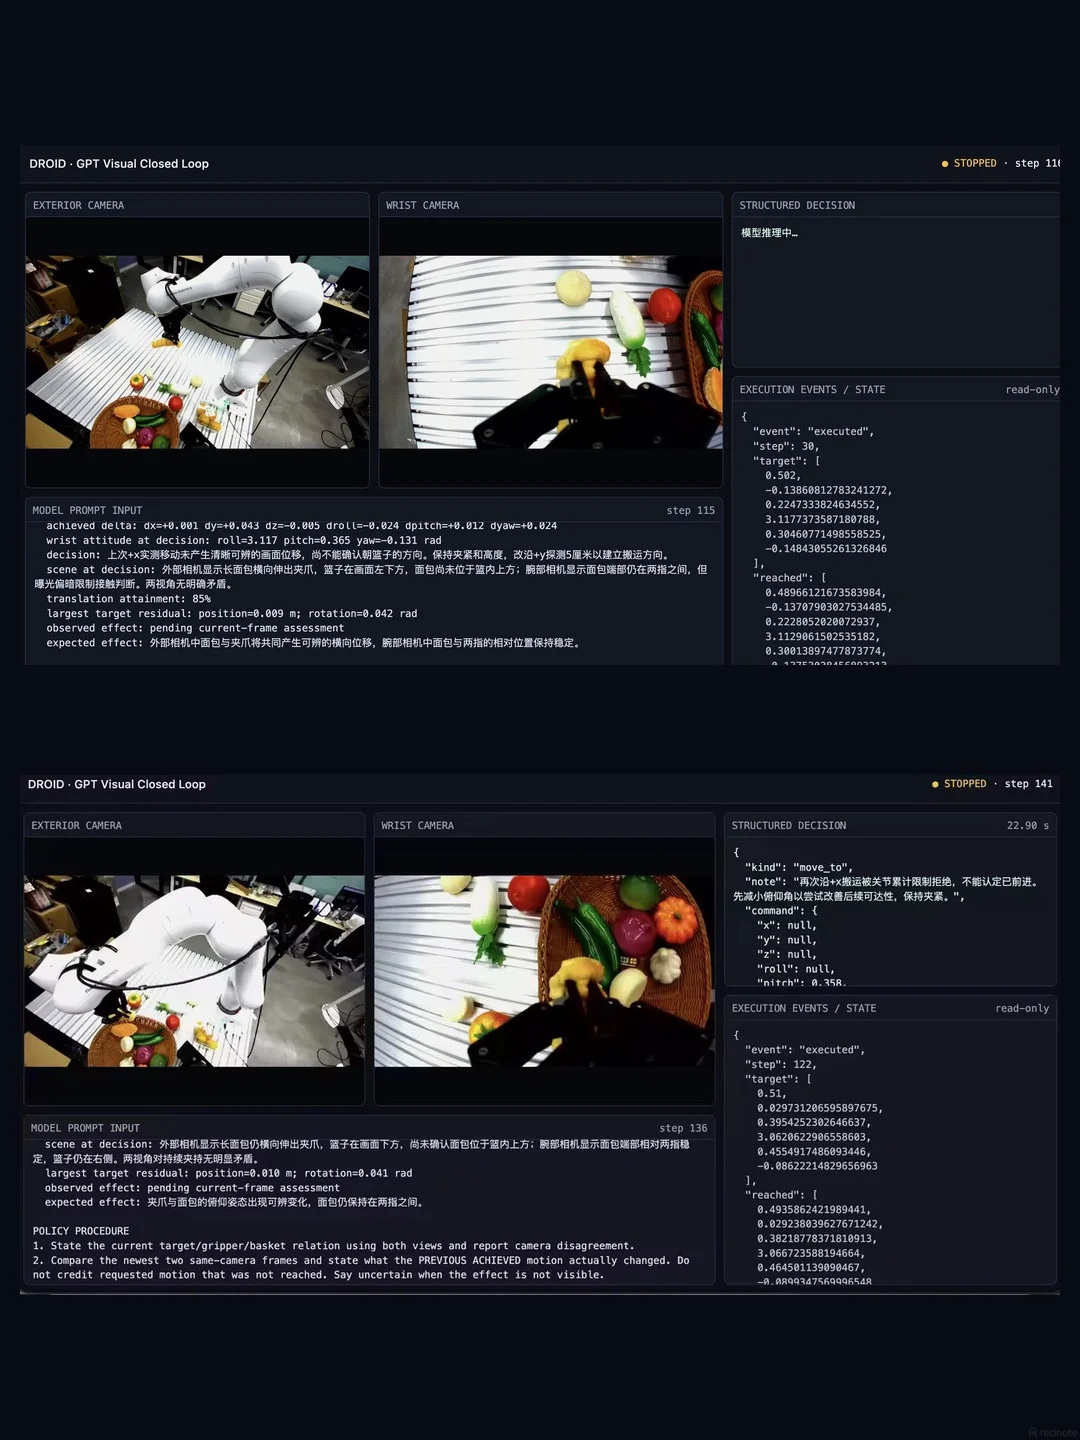
Astra places the longest piece of bread into a basket using third-person and wrist cameras.
Source / Credit: 虽然不但是, Rednote demo using only Codex/GPT-6, Piper, and the RealSense SDK.
Published: 2026-09-05
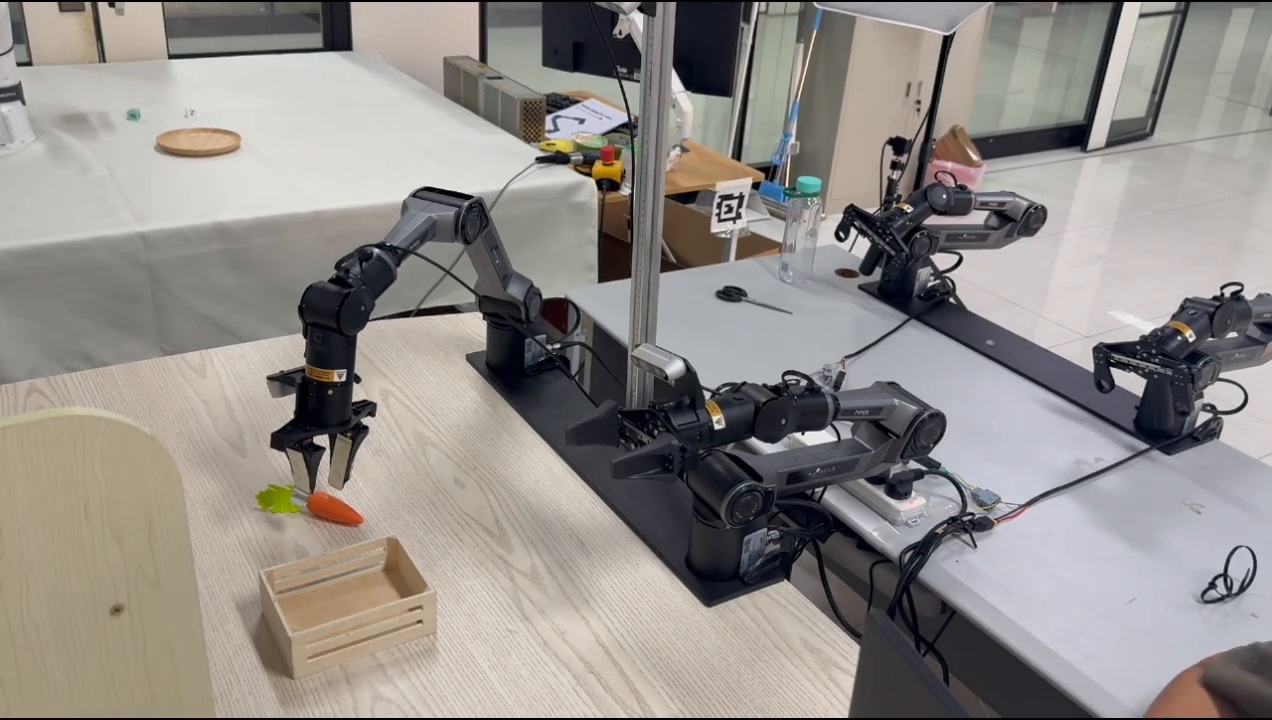
Astra directly controls Piper through repeated visual pick-and-place attempts.
Astra performs high-level task understanding and decomposition, then calls a pretrained embodied foundation model for low-level control.
Source / Credit: Jikun, Rednote demo pairing GPT-6 Astra with the pretrained FluxVLA policy.
Published: 2026-09-09
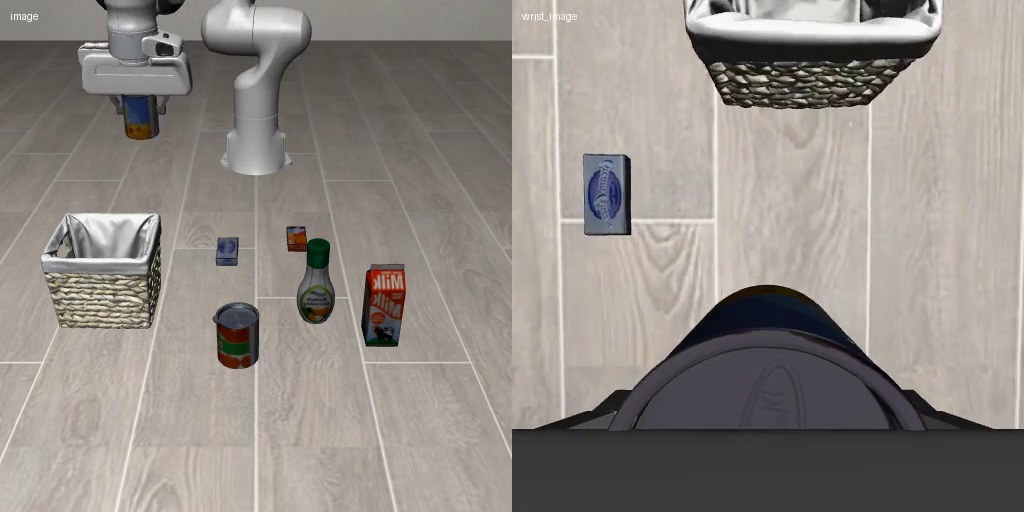
“Zero-shot” refers to Astra’s task inference and planning; FluxVLA executes the low-level embodied actions.
Workflows that reconstruct or replay real-world trajectories, demonstrations, and environments in simulation.
Source / Credit: Frank ZY Dou, Rednote demo reconstructing a lab kitchen from a 20-second monocular RGB video with movable cabinets and other articulated structures.
Published: 2026-09-12
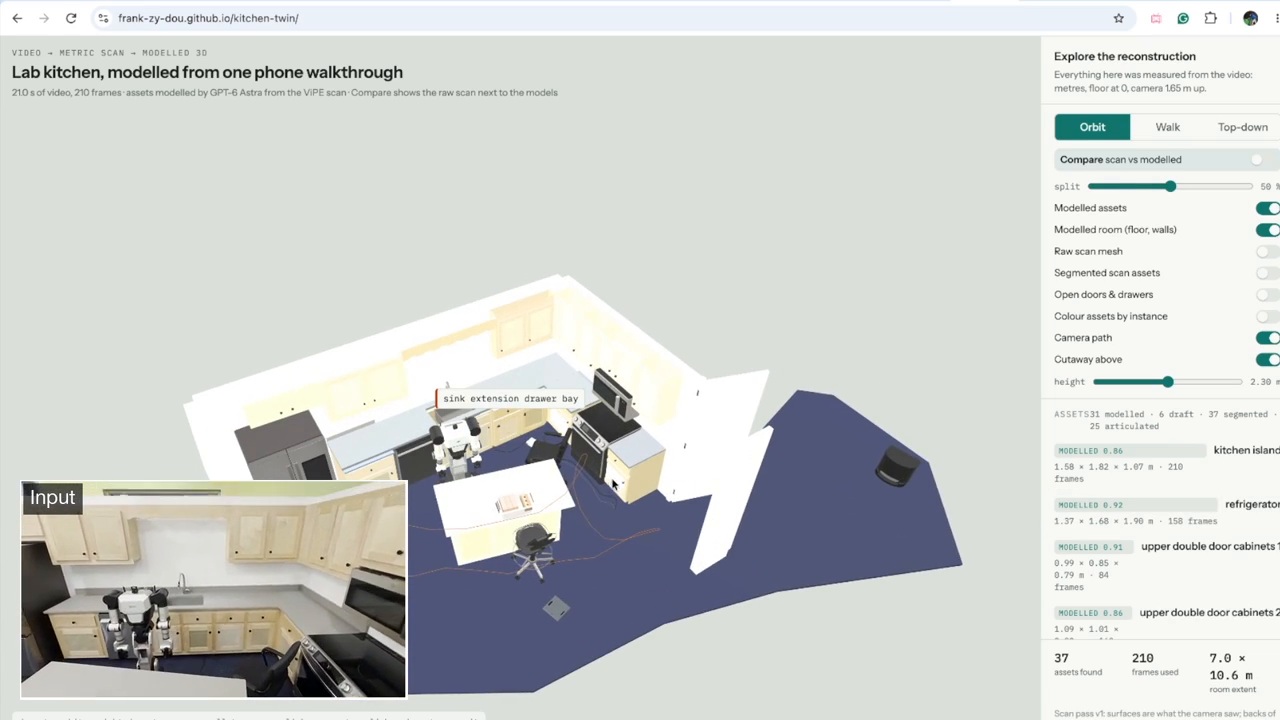
Astra iteratively models a real kitchen and its articulated objects into a simulation scene.
Source / Credit: Dmytro Hrybov (@dimentary), X attempt to recreate 1X's tendon-driven hand demo from a reference video in MuJoCo.
Published: 2026-09-10
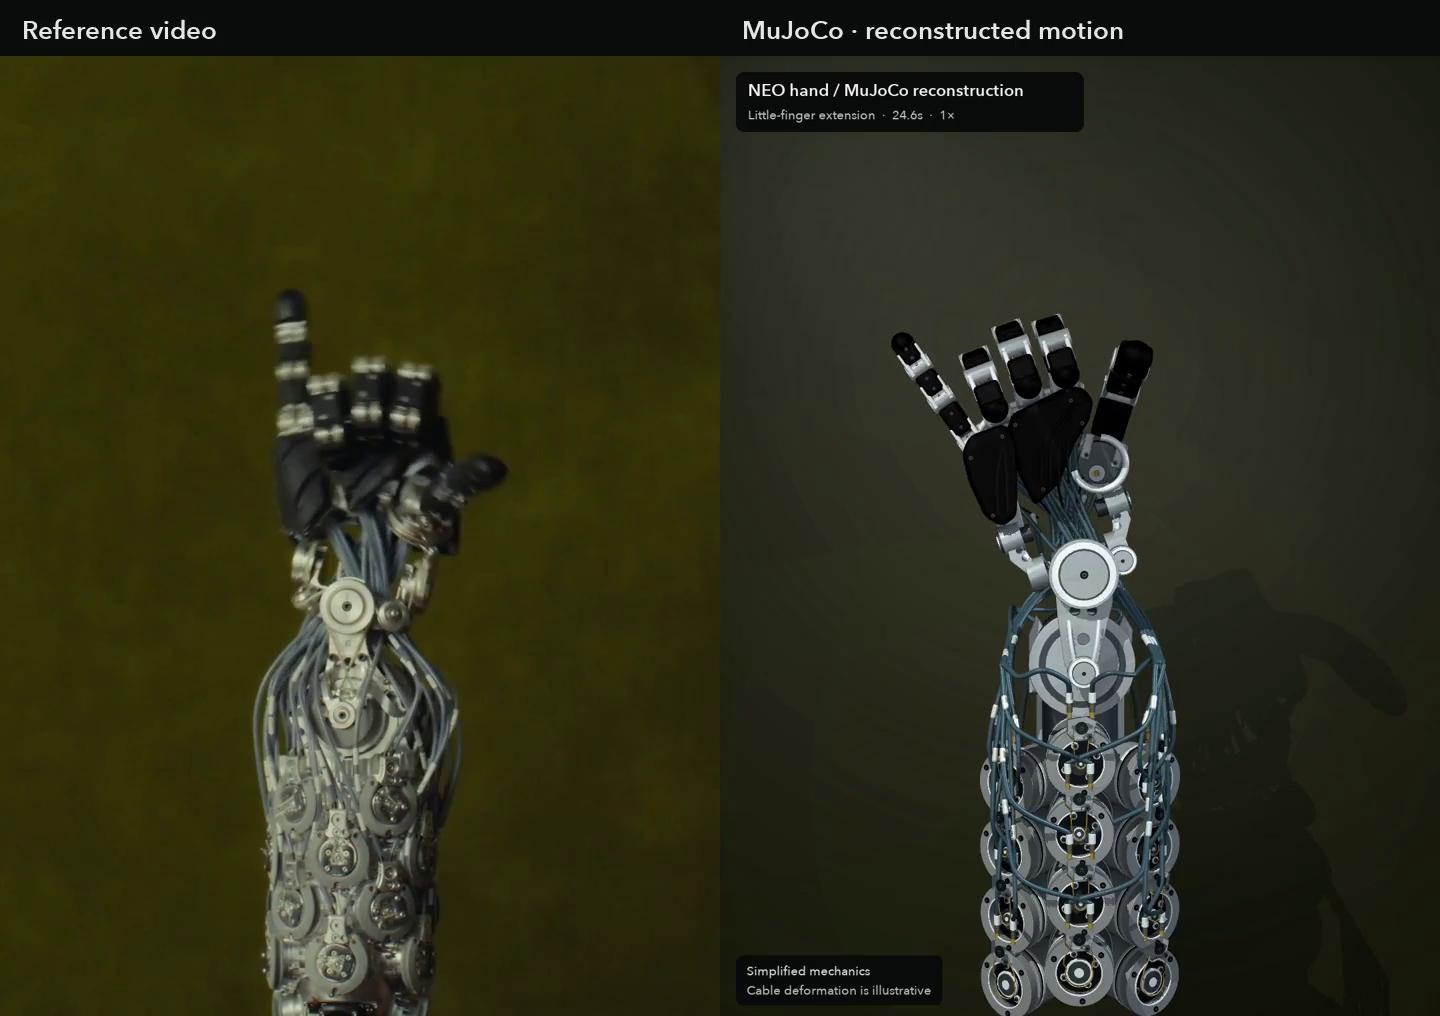
Astra rebuilds the hand and motion, but uses simplified mechanics and illustrative cable deformation rather than full tendon-transmission physics.
Source / Credit: Jake Fitzgerald (@earthtojake), X demo in which Astra designs and reconstructs the motion of a tendon-driven robot hand.
Published: 2026-09-09
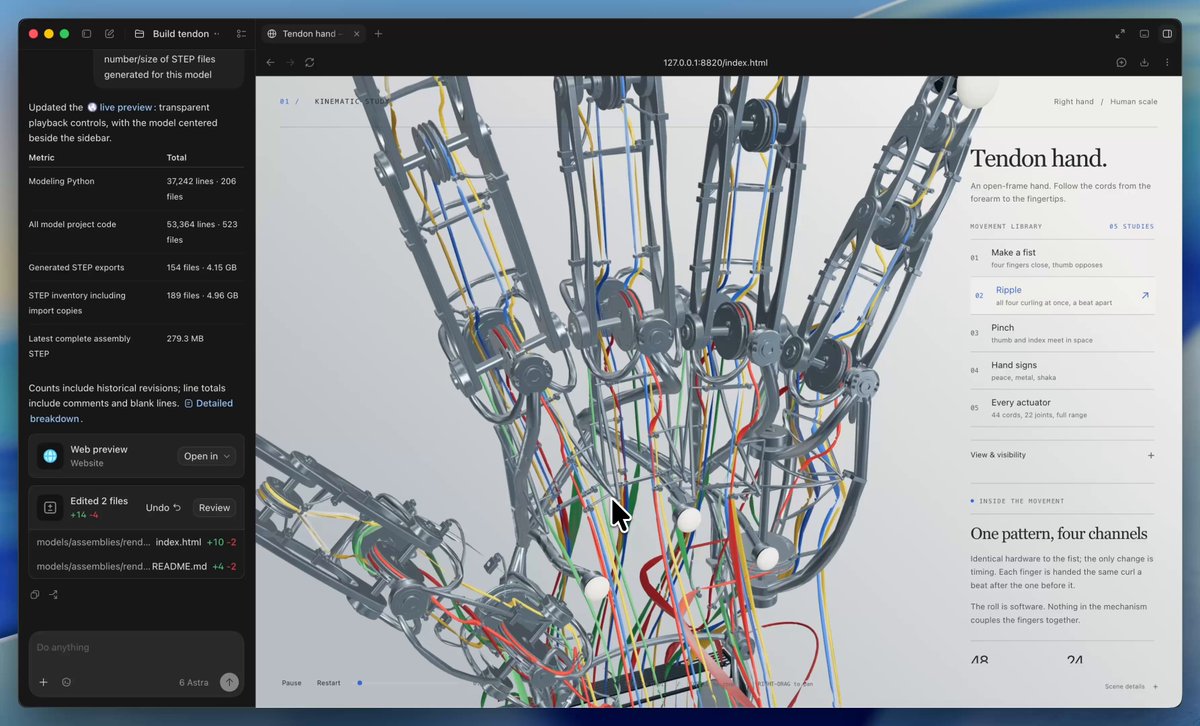
Astra reconstructs the tendon-driven hand's motion in a simulated model, including cable-actuated finger movement.
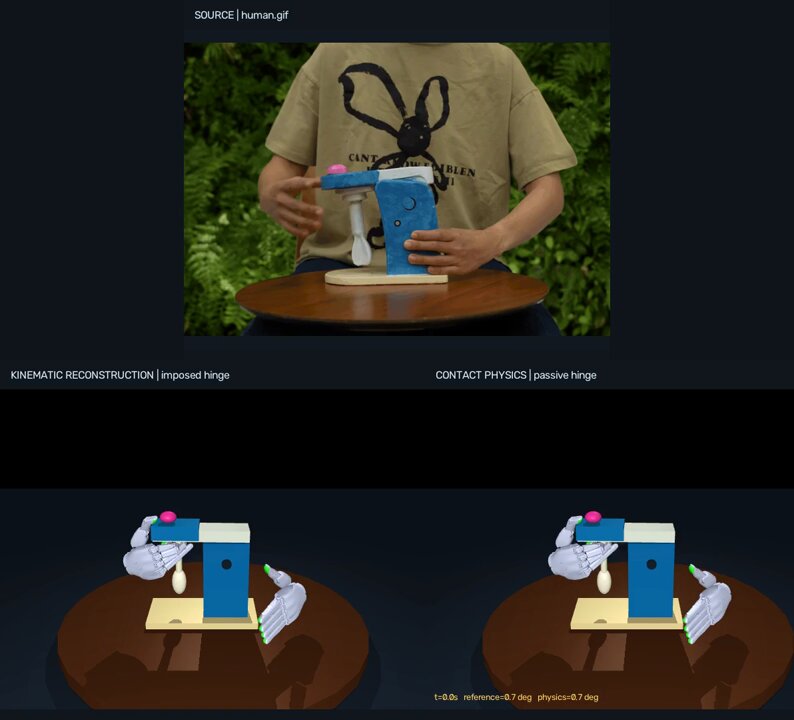
Source / Credit: Lingxiao (@Lingxiao234), X demo showing two videos driving real-to-sim reconstruction and physical retargeting to Wuji hands.
Published: 2026-09-09
Astra reconstructs hand-object interaction from videos without explicit states or actions.
Source / Credit: xiao hu (@huxiao93612565), X demo of Astra writing hand tracking, IK retargeting, and grasp-refinement code for a 44-DOF hand.
Published: 2026-09-09
Astra turns visual hand motion into a physics-backed dexterous-hand replay.
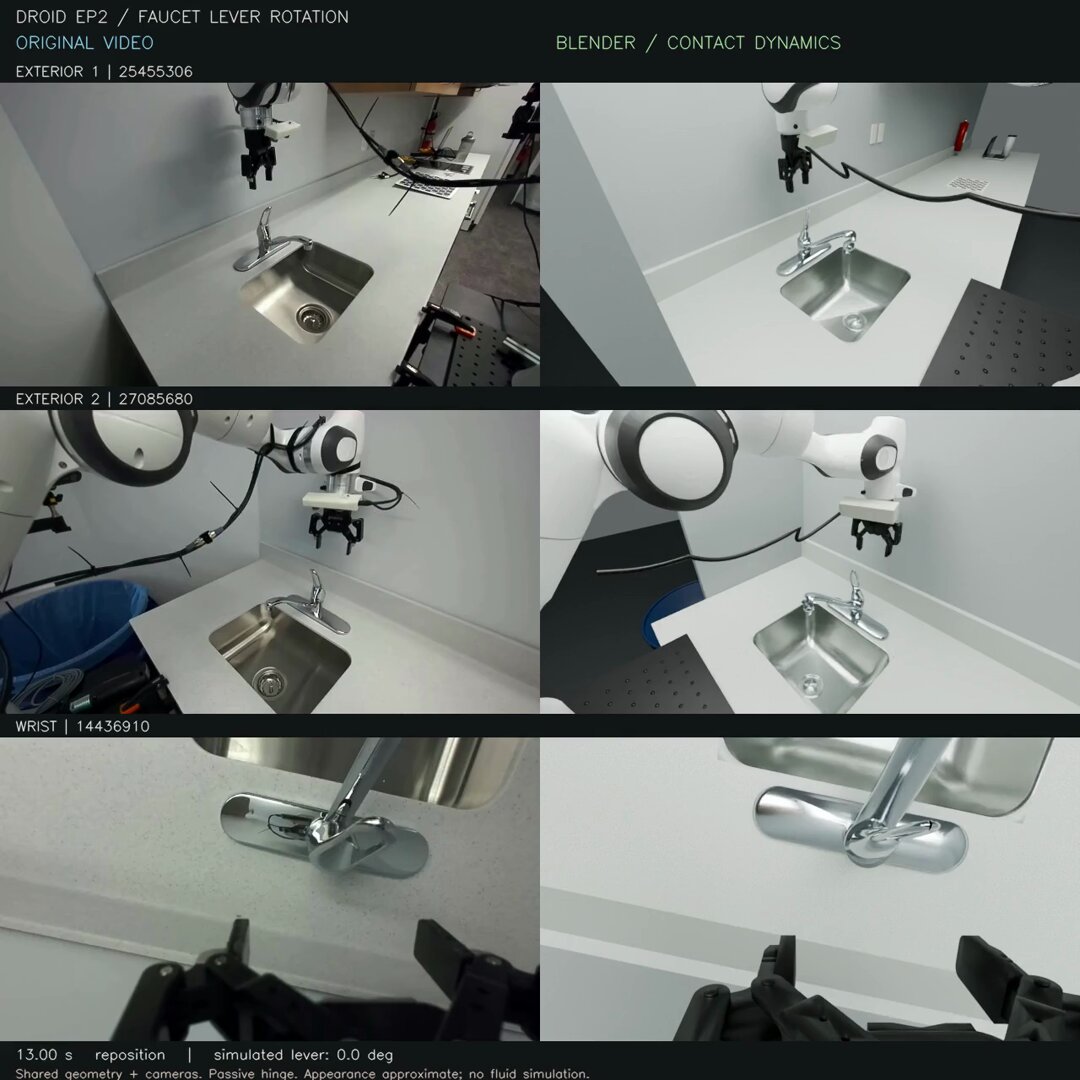
Source / Credit: Lingxiao (@Lingxiao234), X demo combining multi-view RGB, robot actions, camera calibration, assets, system identification, MuJoCo, and Blender.
Published: 2026-09-07
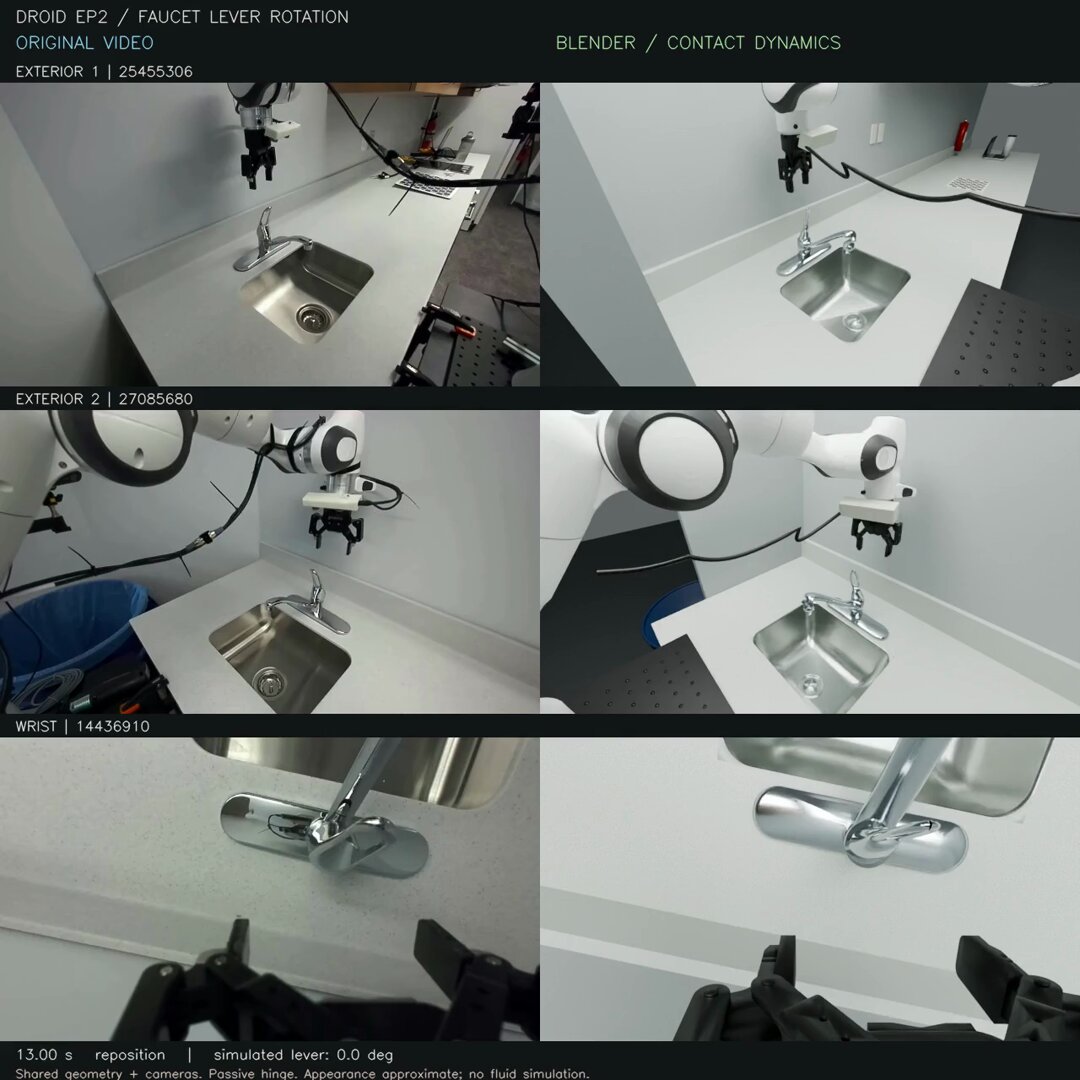
Astra builds a replayable simulator from demonstrations, geometry, and physical parameters.
Workflows where Astra helps create environments, task definitions, training code, and experiment iterations.
Source / Credit: Wentao Zhu (@walterzhu8), X report of an autonomous Astra run by his student Chengyang Li to build and train a dexterous-hand pen-spinning task.
Published: 2026-09-16
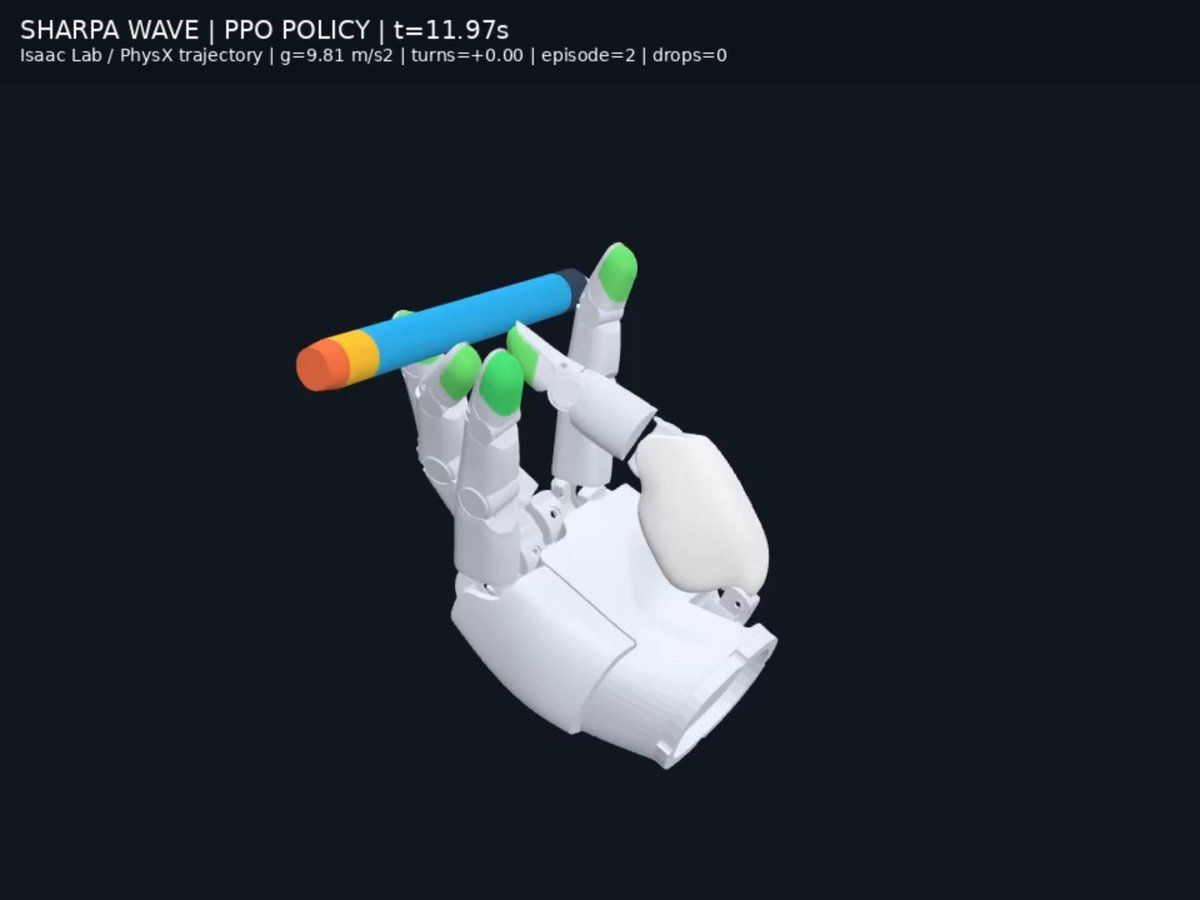
Astra creates the pen mesh, implements the Sharpa-hand task in Isaac Lab, trains the PPO policy, and produces a visualization video during an autonomous run of about a day and a half.
Source / Credit: 拂晓时分_茉莉飘香, Rednote demo reporting an RL-trained duck robot generated from one image and one description.
Published: 2026-09-11
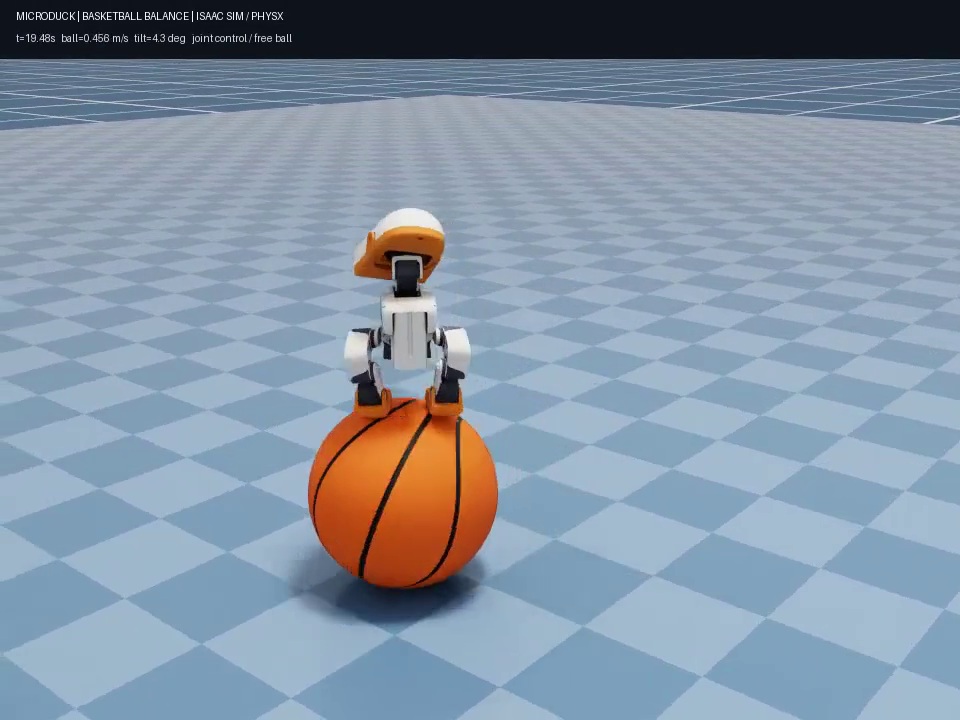
Astra builds and trains a locomotion demo from a compact visual specification.
Source / Credit: Akira Sasaki (@gclue_akira), X report of Astra designing a robot dog, iterating 25 loops in five days, and training nine motions with RL.
Published: 2026-09-11
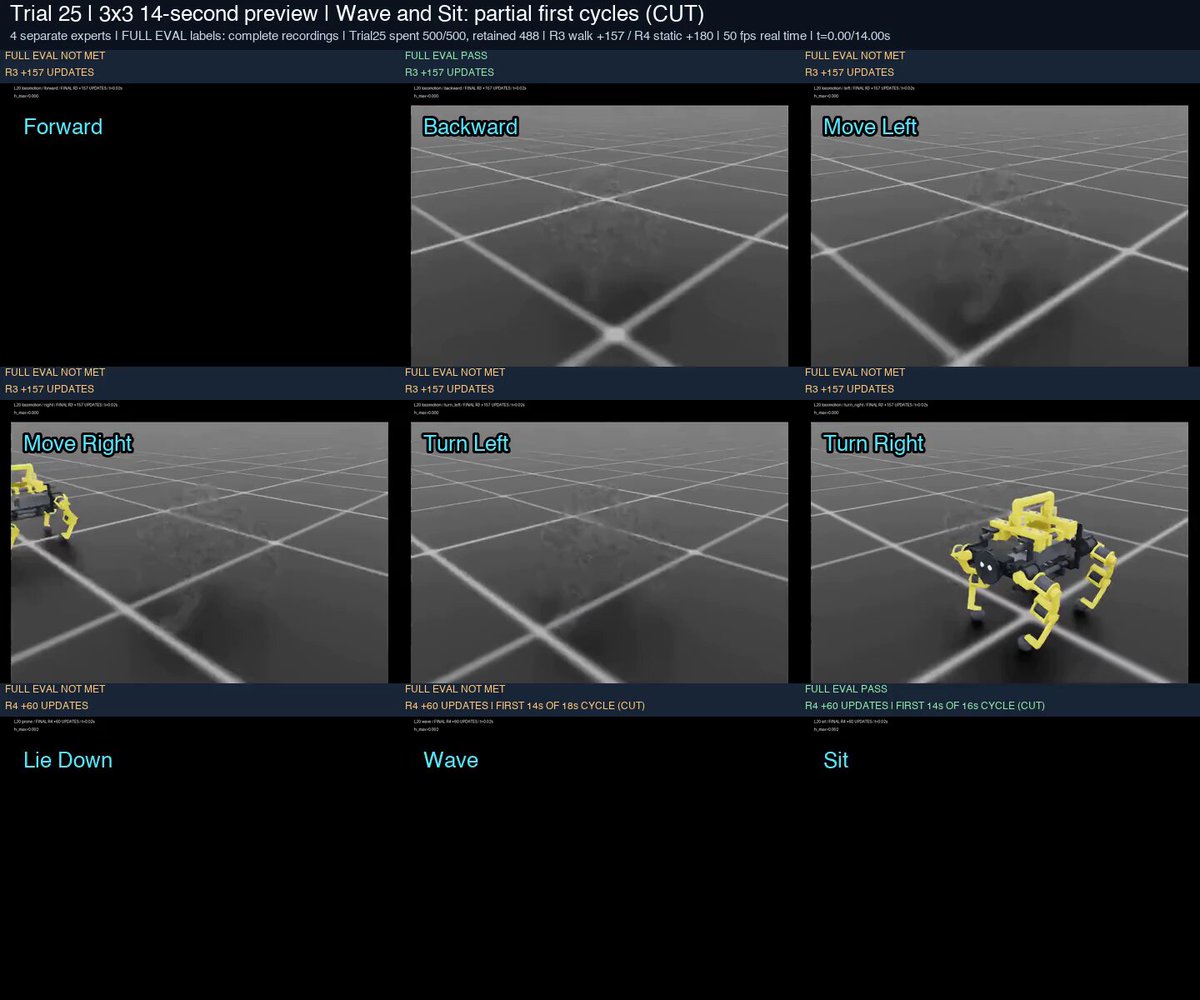
Astra co-designs the quadruped and trains a simulated locomotion system; real-hardware debugging is planned rather than completed.
Source / Credit: 十一, Rednote RL demo of a dexterous hand manipulating a walnut; self-collision was not enabled in the reported run.
Published: 2026-09-11
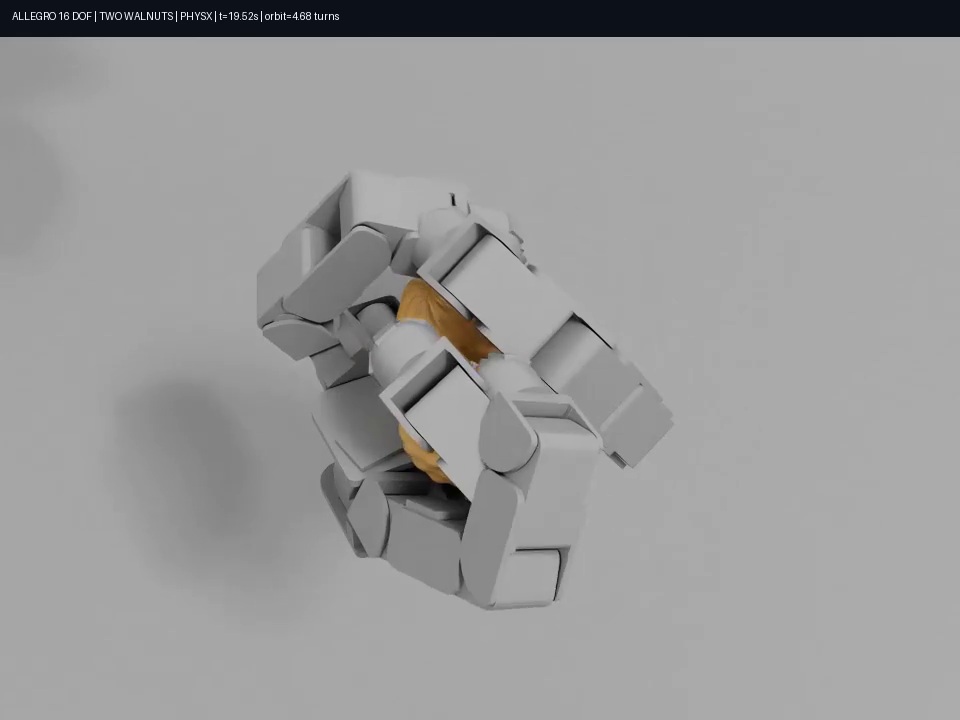
Astra trains the in-hand manipulation behavior while exposing the reported collision-model limitation.
Source / Credit: Jiarui Xu (@Jiarui_X), X demo where Astra rebuilds an office scan in Blender, exports USD, and creates a G1 walking scene in Newton.
Published: 2026-09-11
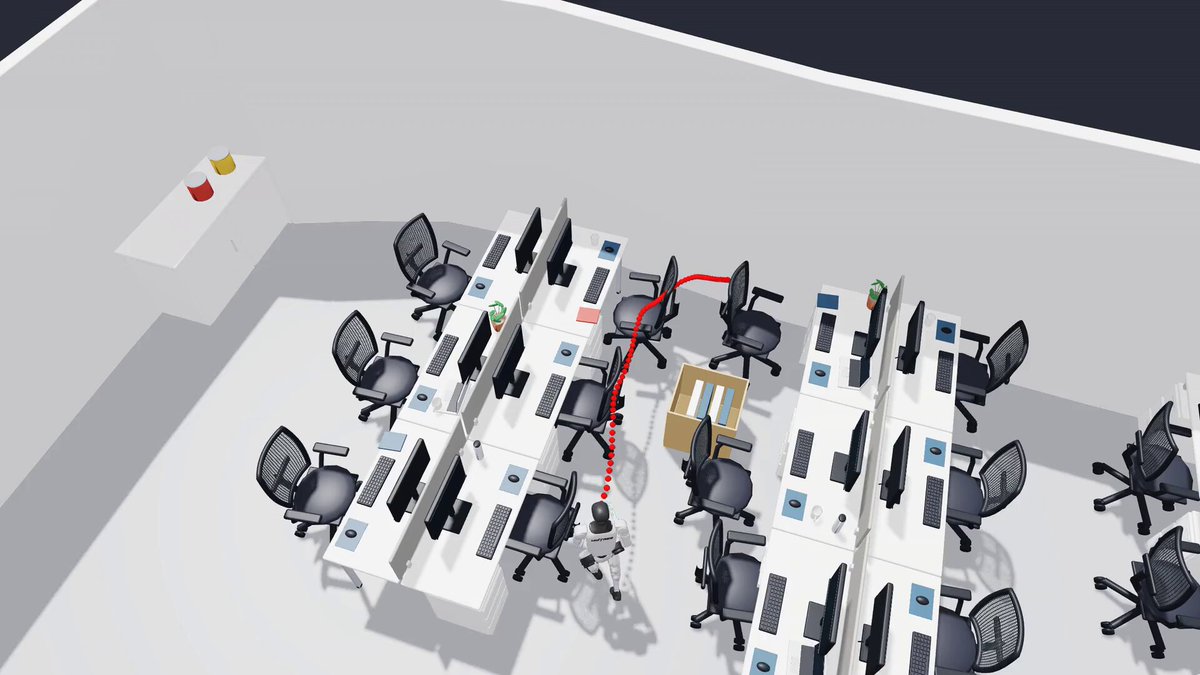
Astra creates the environment and training-ready humanoid simulation scene.
Source / Credit: 十一, Rednote demo of Astra building an Isaac Sim RL environment, configuring PPO, and tuning the run.
Published: 2026-09-10
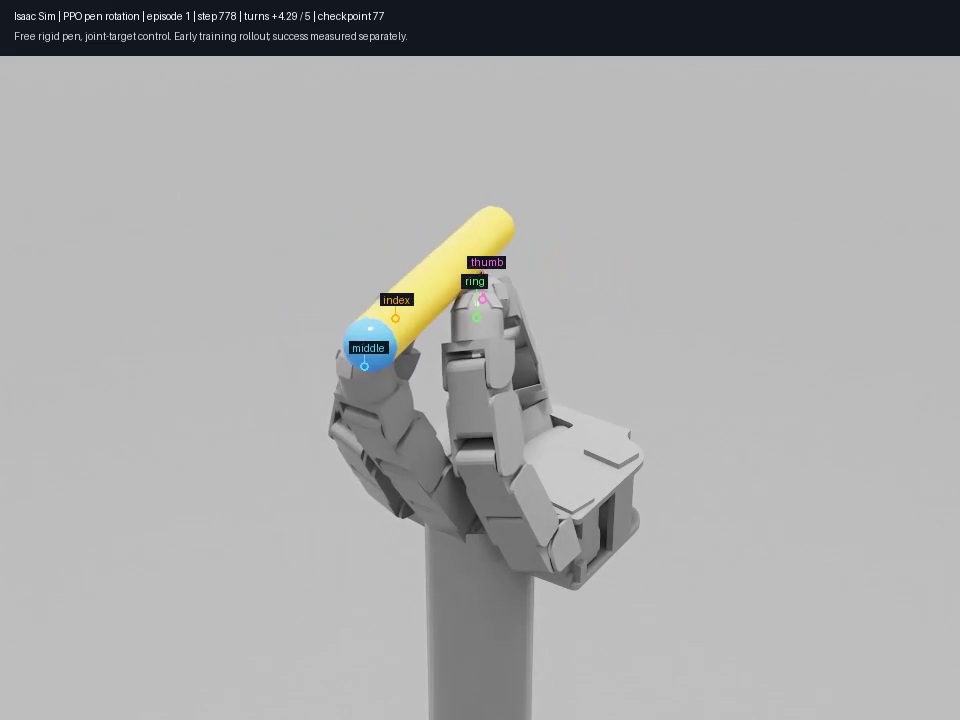
Astra handles environment construction, training configuration, and iteration in one workflow.
These entries index representative partial or unsuccessful outcomes. A failure can reflect modeling, calibration, embodiment, or tool limits in one setup and does not prove that Astra lacks the underlying capability.
Public evaluation repositories and result reports for GPT-6 Astra in embodied-AI settings. Results below are reported by the respective maintainers and should be interpreted within each project's disclosed hardware, task, and evaluation protocol.
→ →
 →
 →
 →
 →
 →
 →