
1
 →
MirroS-Lab/AgentGarten is an open-source project on GitHub, mainly written in Python. AgentGarten: Code Worlds for Evolving Agents It currently holds 145 stars and 3 forks with 0 open issues, and was last pushed on an unknown date (repository created unknown).
AI Homed tracks it on the Today's Trending board, currently at rank #89 with 0 new stars today.
Code Worlds for Evolving Agents
Code determines how the world changes, and the renderer learns how those changes should look.
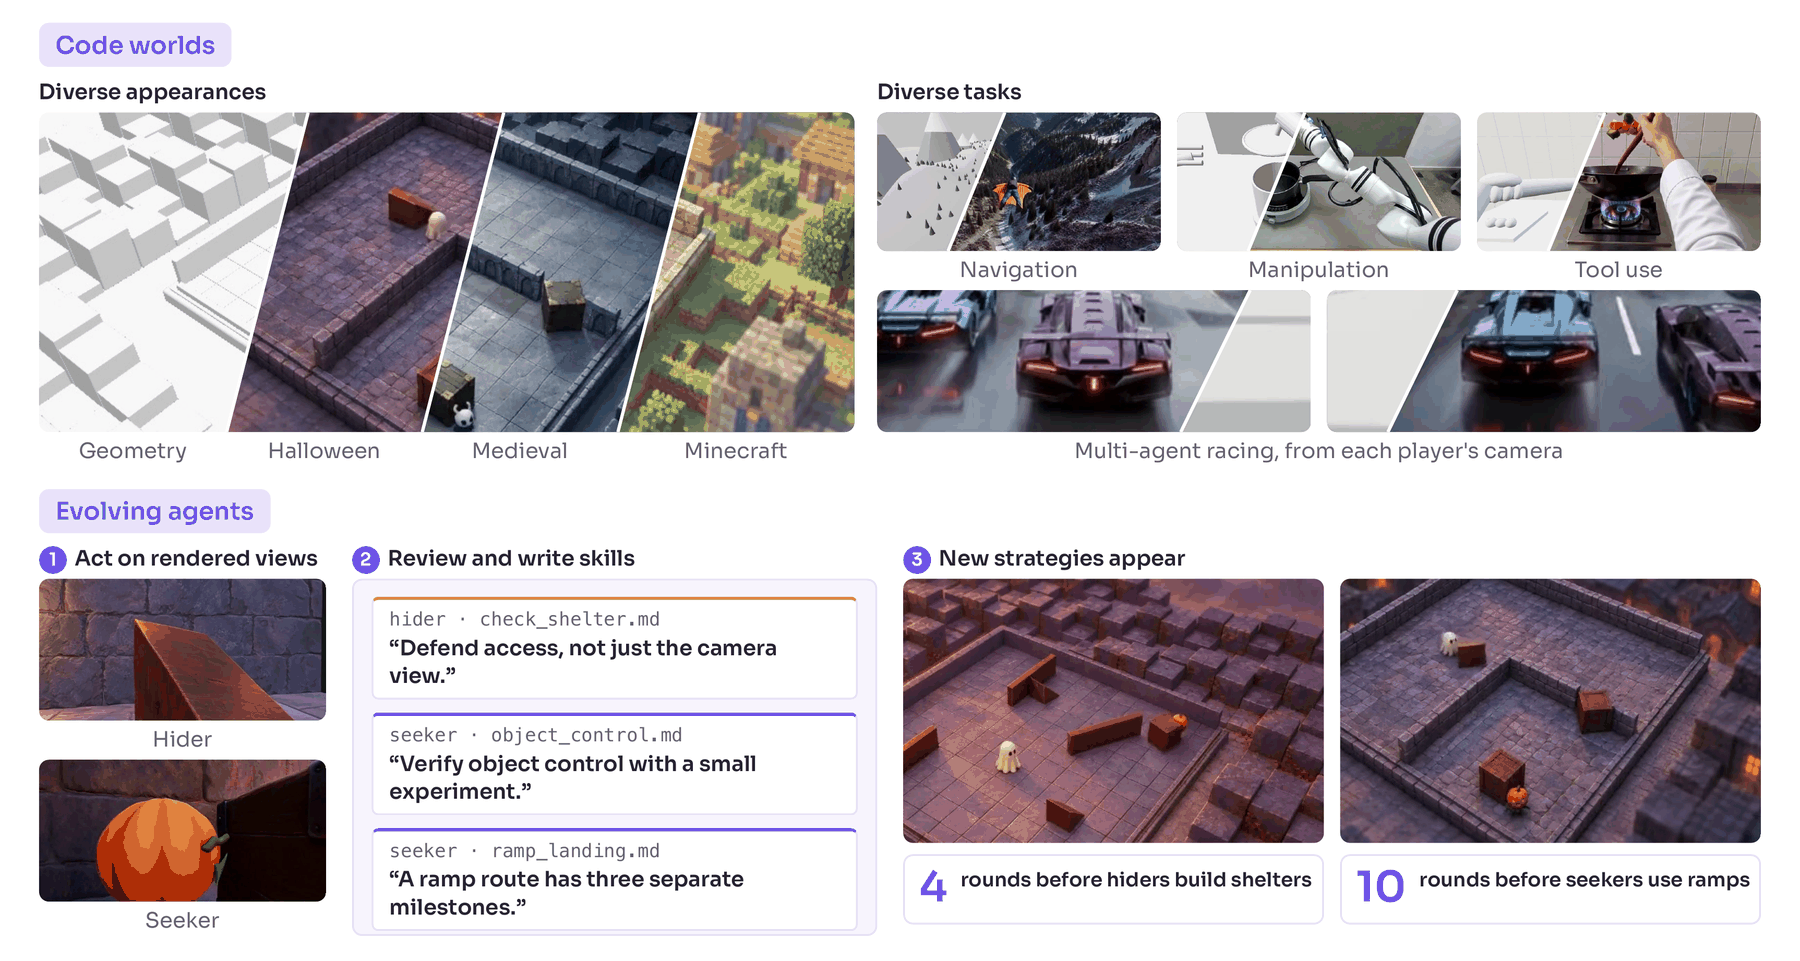
Agents learn through interaction, and what they can learn is bounded by the environment they practice in. That environment must be faithful, with state, rules, and dynamics as consistent as those of the real world, and realistic, with observations that follow the real world's visual distribution.
AgentGarten builds real-time interactive environments that are both. Simulators and game engines maintain persistent state and execute program-defined rules, while a shared neural renderer generates the agent's observations from the depth and surface normals each world exports. Agents that practice in these environments improve from their own experience: after each round they distill what happened into playbooks that later agents inherit and build upon.
This is the official repository of AgentGarten. The neural renderer is available now, with its training recipes and streaming inference; the code worlds and the agent practice loop will be released here as well. The renderer adapts Cosmos3-Nano to geometry conditions in three stages:
Python 3.11+ and PyTorch 2.9+ on a CUDA host.
git clone https://github.com/MirroS-Lab/AgentGarten.git
cd AgentGarten
pip install -e '.[data,media,wandb,te]'
cp .env.example .env    # weights, manifests, output root, interpreter
Training starts from Cosmos3-Nano and encodes video with the Wan 2.2 VAE:
hf download nvidia/Cosmos3-Nano \
  --include 'transformer/' 'text_tokenizer/' 'assets/negative_prompt.json' \
  --local-dir weights/Cosmos3-Nano
hf download Wan-AI/Wan2.2-TI2V-5B Wan2.2_VAE.pth --local-dir weights/Wan2.2-TI2V-5B
Point WM_COSMOS3_NANO and WM_WAN22_VAE in .env at them.
Cosmos3Stream runs the renderer block by block with a bounded KV cache.
Each block is denoised in a few steps and then committed to the cache, so the
conditions of the next block can depend on what was just generated:
import torch
from wm.inference.cosmos3 import inspect_artifact, load_artifact
from wm.inference.serving import prepare_serving
from wm.models.dmd import RCM_ENDPOINTS
from wm.models.flow import rf_interpolate, rf_x0
from wm.networks.cosmos3.streaming import Cosmos3Stream, StreamPolicy
artifact = load_artifact(inspect_artifact("weights/AgentGarten-renderer"))
prepare_serving(artifact.student)    # serving kernels and CUDA graphs
stream = Cosmos3Stream(artifact.student, StreamPolicy())
anchor: the clean first-frame latent; every condition holds the text context
and the depth and normal latents of one chunk.
stream.start(anchor, first_condition)
block = (1, anchor.shape[1], stream.policy.block_frames, *anchor.shape[3:])
for condition in blocks:    # one block is 4 latent frames
    clean = None
    for sigma in RCM_ENDPOINTS:
        sigma = torch.tensor([sigma], device=anchor.device)
        noise = torch.randn(block, device=anchor.device, dtype=anchor.dtype)
        noisy = noise if clean is None else rf_interpolate(clean, noise, sigma)
        clean = rf_x0(noisy, sigma, stream.denoise(noisy, sigma, condition))
    stream.commit(clean, condition)
prepare_serving serves the transformer with hand-written Triton kernels,
cuBLAS matrix products, and CUDA graphs, without torch.compile. Kernel JIT
and graph capture happen on first use, so warm the input shapes before
serving.
To render the validation clips of a checkpoint without training, add
`train.max_iterations=0 train.validate_at_start=true
trainer.callbacks.samples.every_n=1` to its training command. Comparison
videos (depth, normal, ground truth, sample) are written under samples/.
To decode RGB faster, attach the
TAEHV taew2_2_super.pth decoder with
one more override; encoding stays on the Wan encoder:
model.conditioner.codec.decoder={_target_:wm.codecs.TAEW22SuperDecoder,pretrained_path:/path/to/taew2_2_super.pth}
Data. A JSONL manifest, one clip per line, with paths relative to the manifest:
{"video": "clips/0001.mp4", "depth": "clips/0001_depth.npy", "normal": "clips/0001_normal.mp4",
 "caption": "A car drives along a coastal road.", "depth_scale": 1.0}
Launch.
bash scripts/run.sh experiment=cosmos3/bidirectional                         # one node, all GPUs
NNODES=4 NODE_RANK=0 MASTER_ADDR=host0 bash scripts/run.sh experiment=...    # on every node
We sincerely thank the teams behind the following projects for making their work available to the community:
| Component | Projects | |---|---| | Base video model | Cosmos 3 | | Video autoencoder | Wan 2.2, TAEHV | | Distillation | DMD2, Self Forcing, rCM |
_... and many other excellent open-source projects._
If you find AgentGarten useful, please cite:
@article{mirros2026agentgarten,
  title   = {AgentGarten: Code Worlds for Evolving Agents},
  author  = {{MirroS Team}},
  journal = {arXiv preprint arXiv:2610.12374},
  year    = {2026}
}
 →
 →
 →
 →
 →
 →
 →